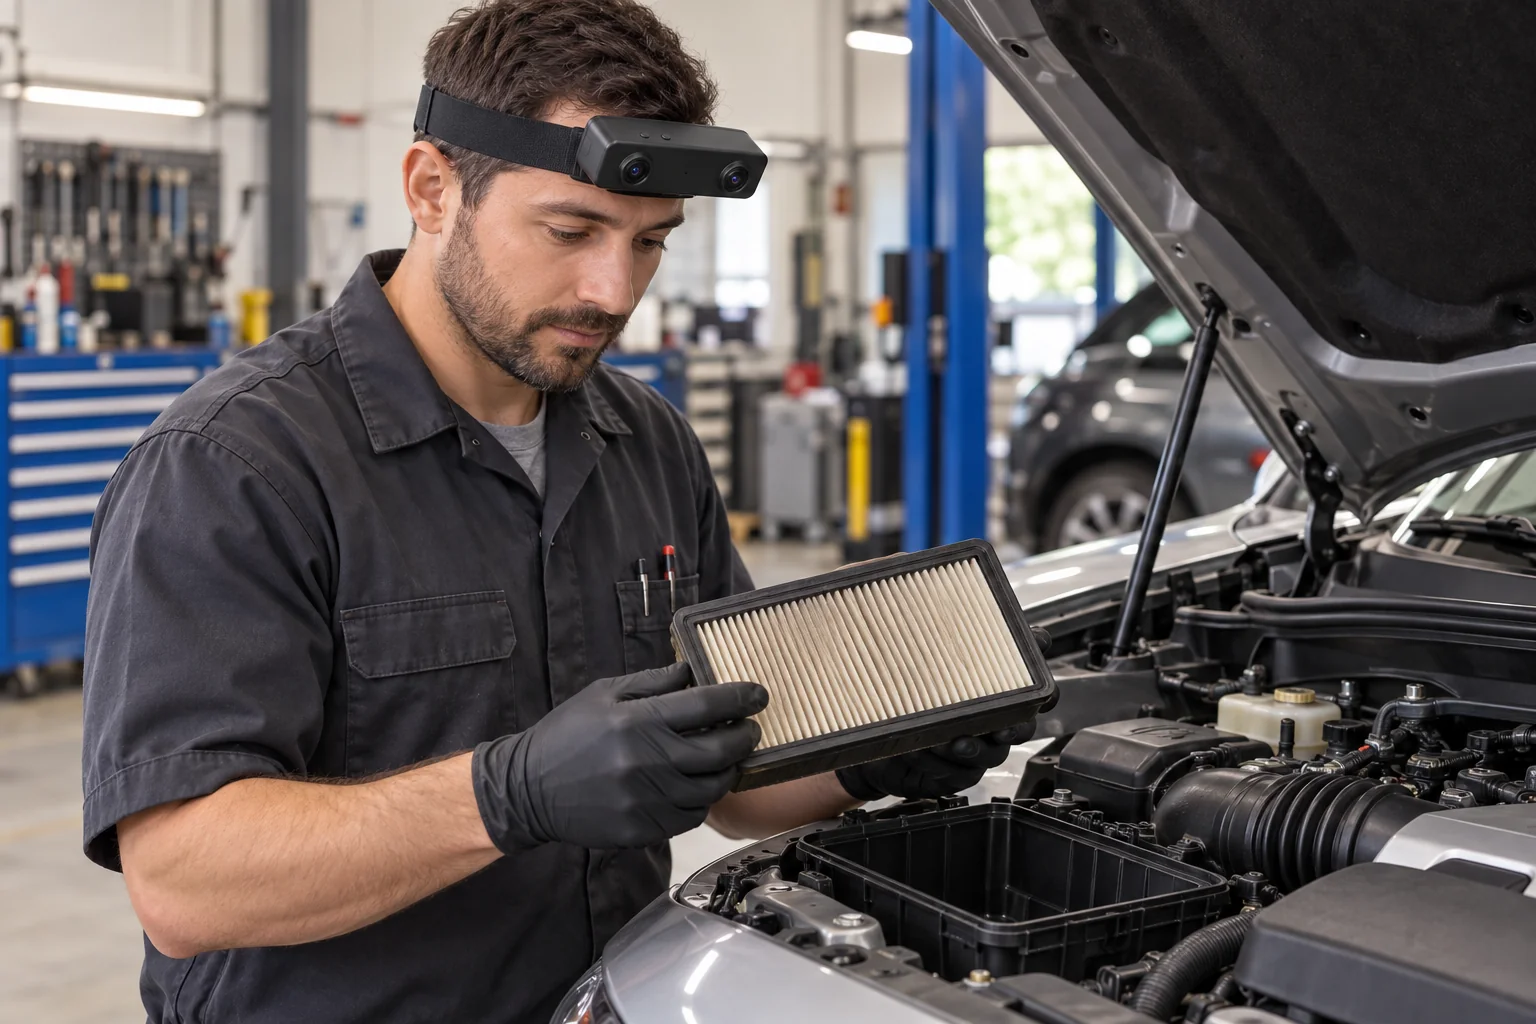
EGO R8 for Automotive Repair and Maintenance Capture
Plan automotive repair and maintenance recordings with EGO R8: synchronized global-shutter stereo, selectable IMU rates, timestamps and USB capture settings.
Read detailsLatest Blog / Sep 24, 2026
Plan automotive repair and maintenance recordings with EGO R8: synchronized global-shutter stereo, selectable IMU rates, timestamps and USB capture settings.
Read latest blog
All Blogs / Newest first
Every article keeps its author, source, publication date, image, and local detail page.
Plan automotive repair and maintenance recordings with EGO R8: synchronized global-shutter stereo, selectable IMU rates, timestamps and USB capture settings.
Read details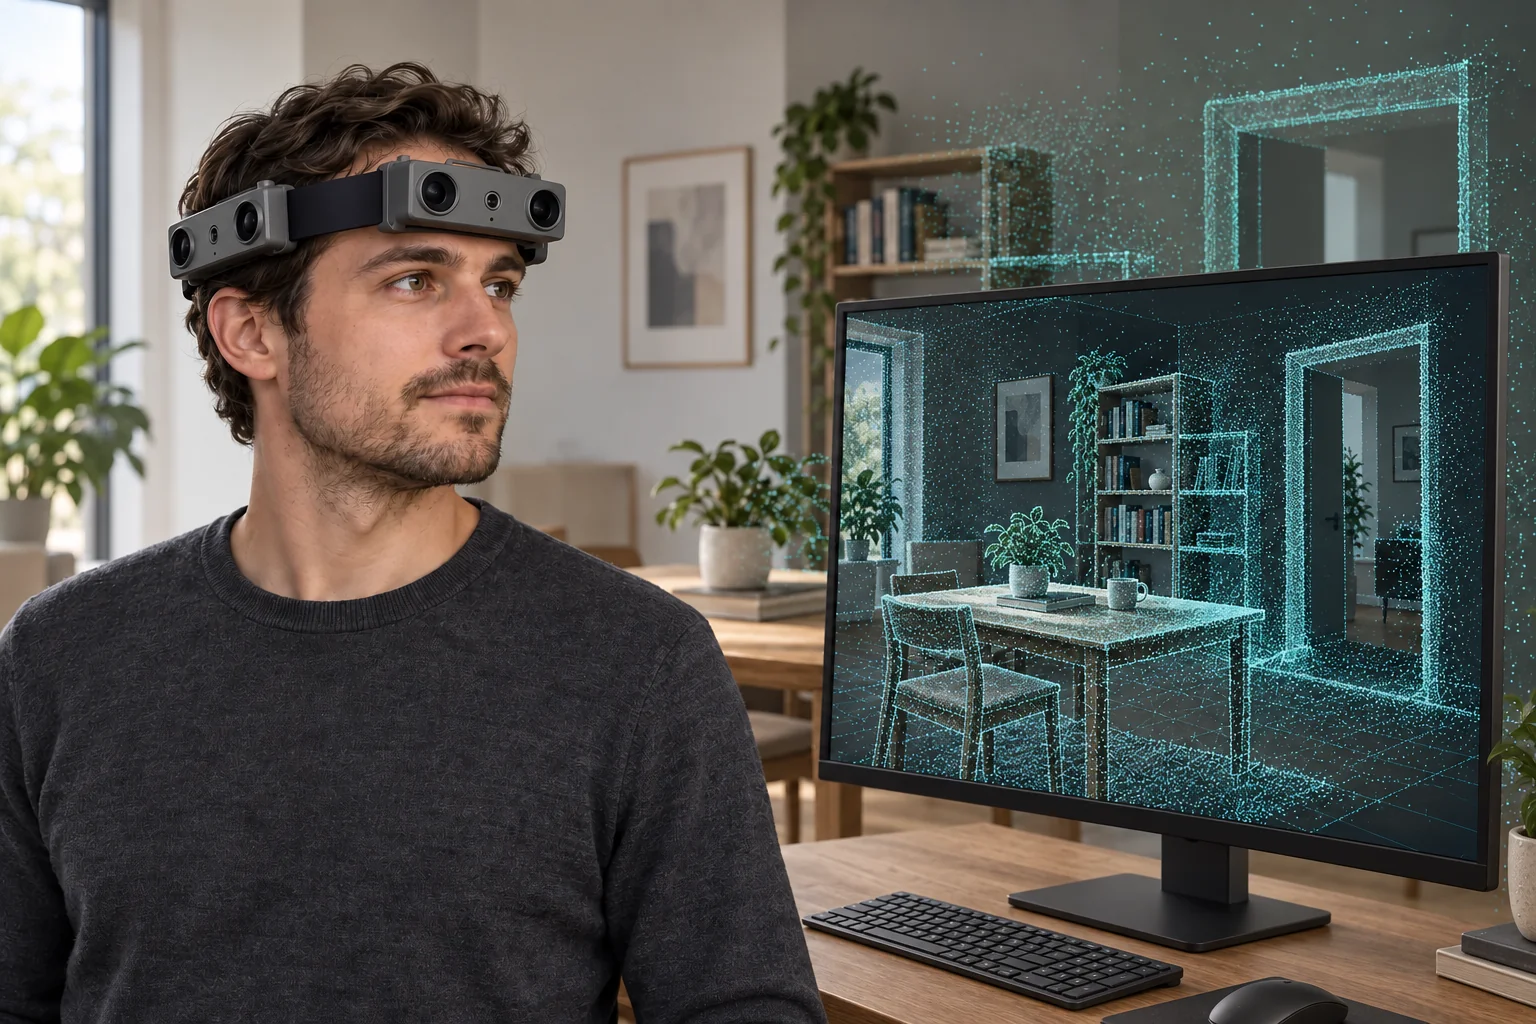
Explore EGO R10 for spatial perception and 3D scene reconstruction: camera hardware synchronization, 1600 × 1200 imaging, stereo functions and IMU options.
Read details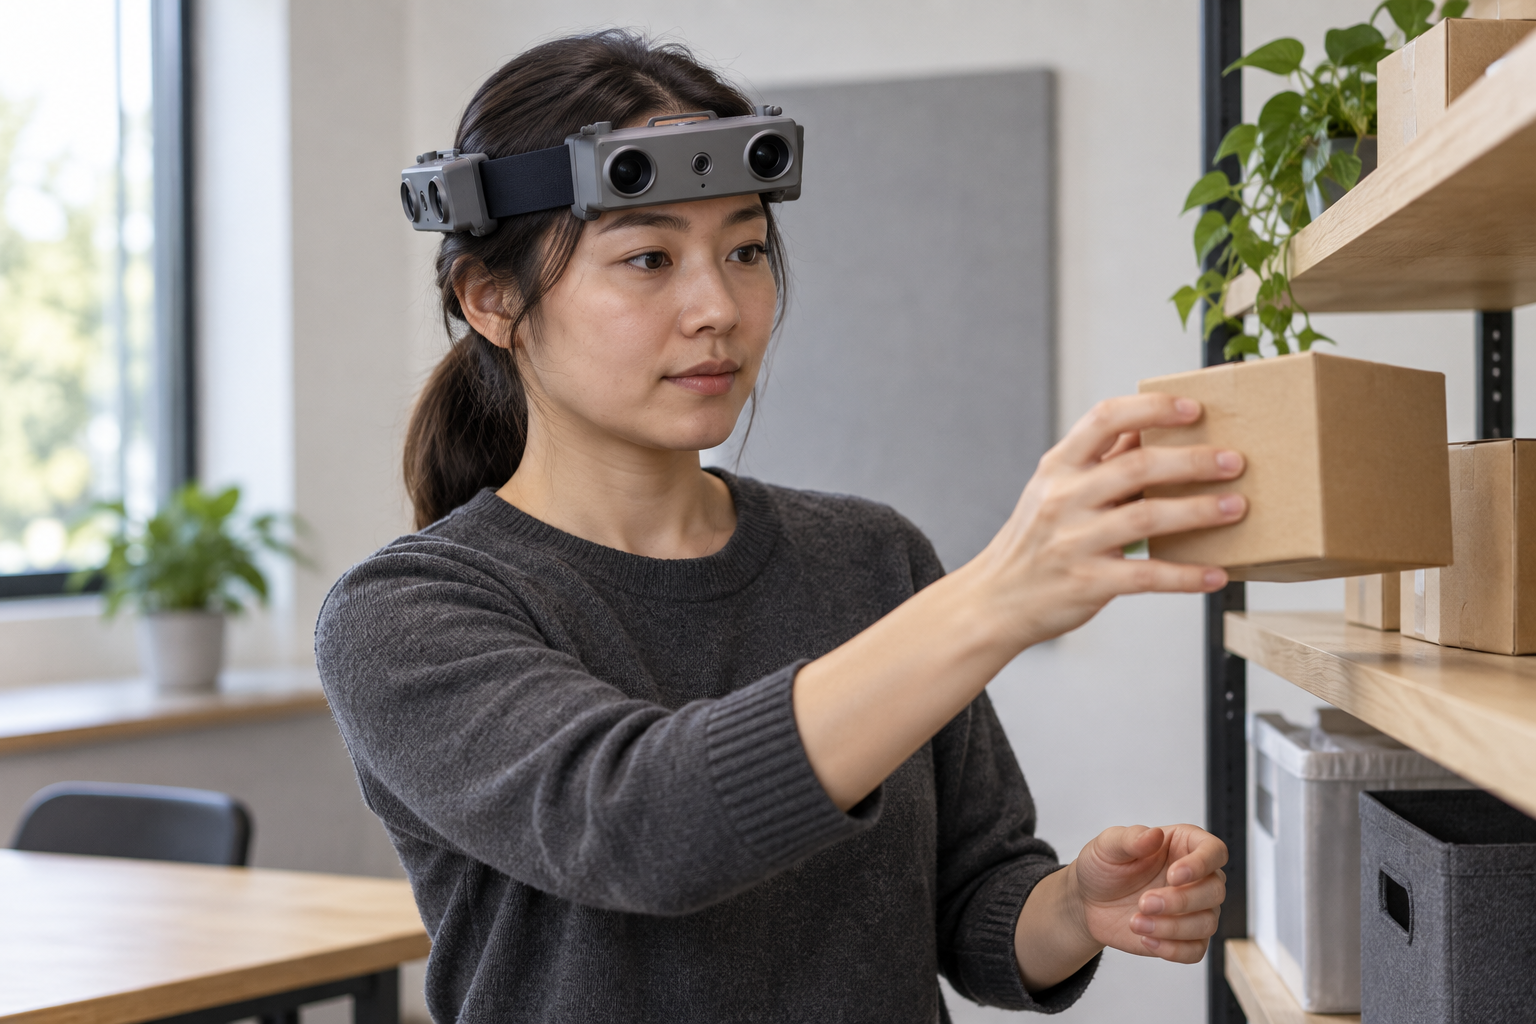
Plan indoor embodied-AI data collection with EGO R10: synchronized multi-camera video, documented imaging settings, IMU options and researcher-created labels.
Read details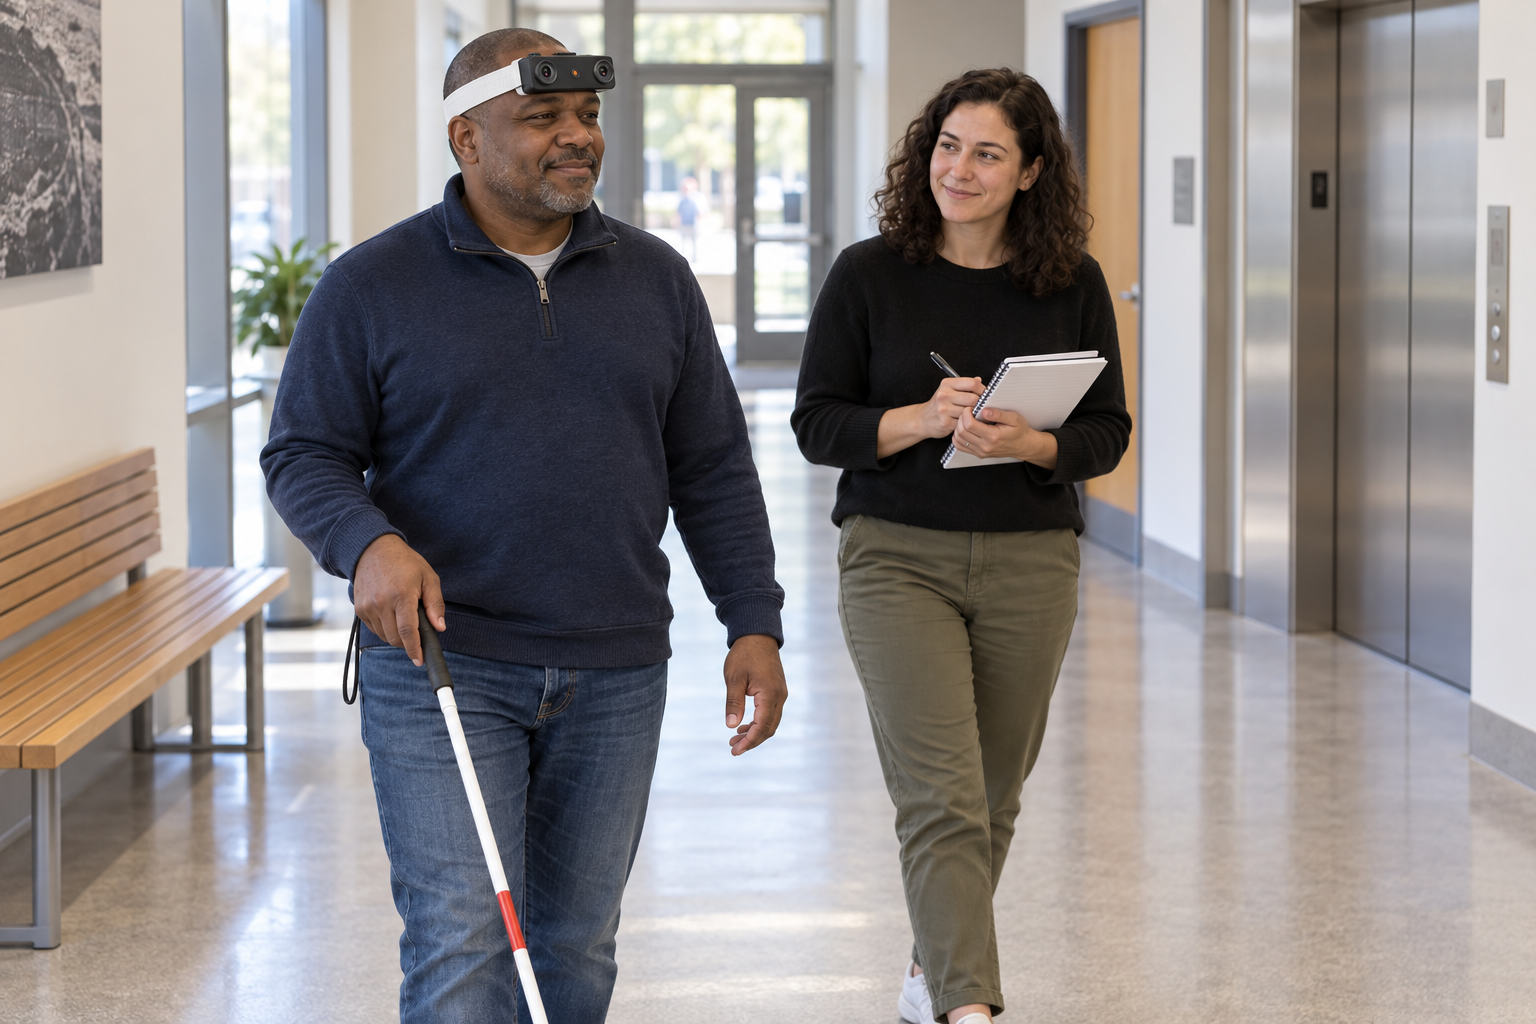
Collect first-person indoor data for blind and low-vision research with EGO R9. Plan video, IMU recording and manual labels for doors, stairs and corridors.
Read details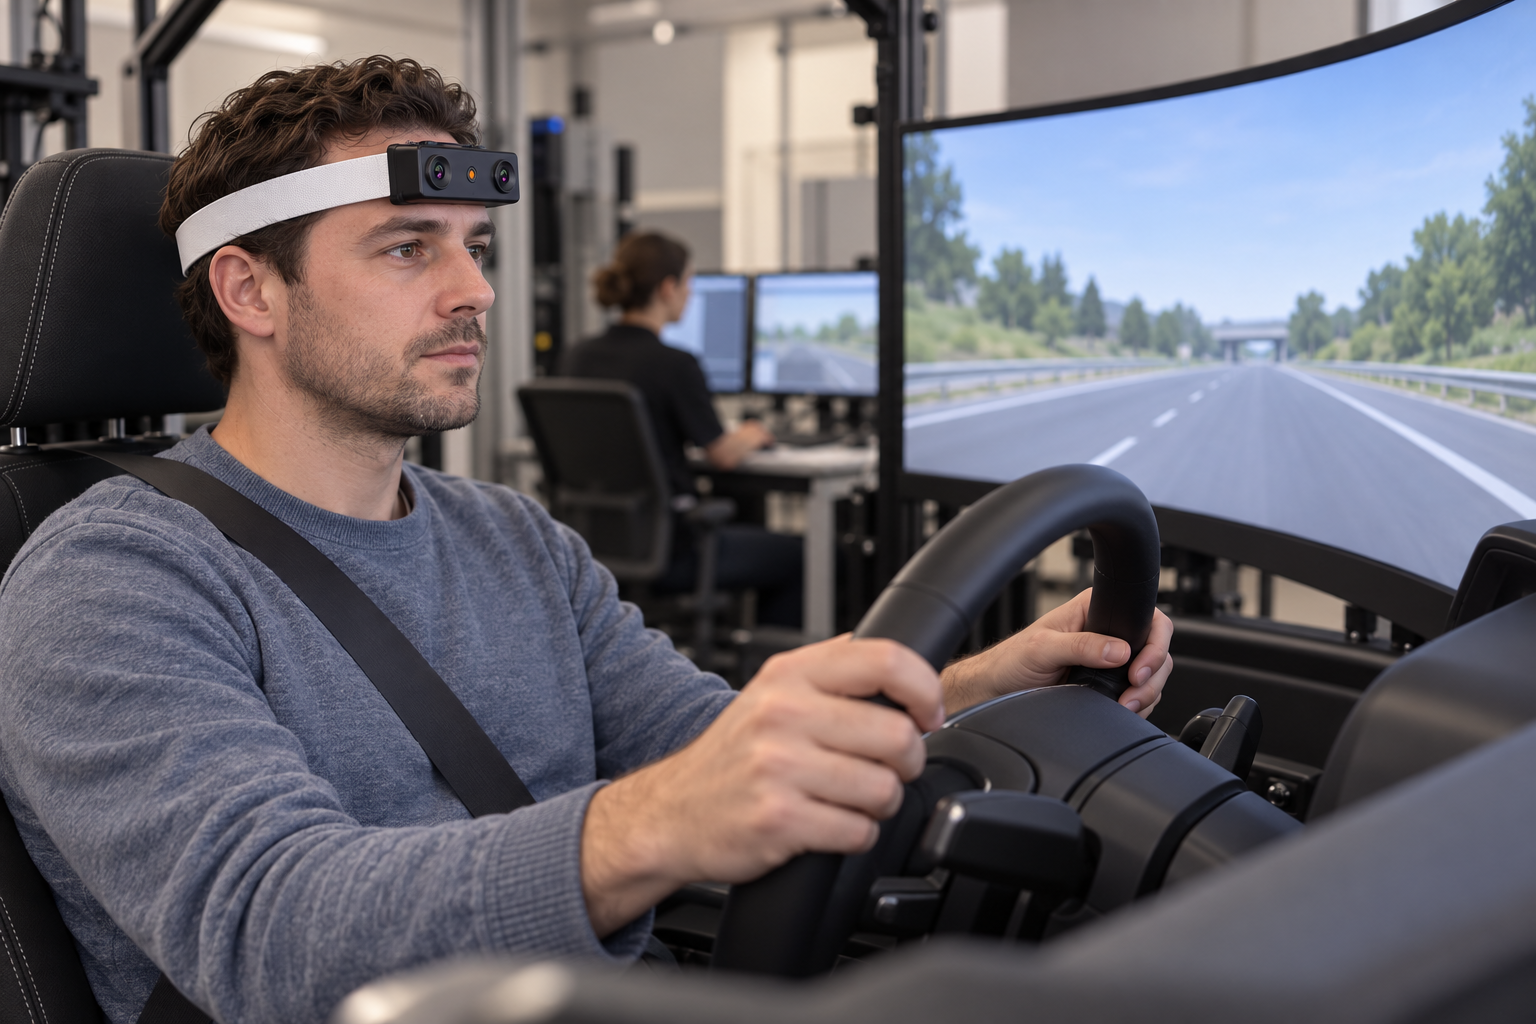
Plan driver takeover dataset capture with EGO R9 video and 6-axis IMU data. Learn simulator setup, event timing and manual annotation steps.
Read details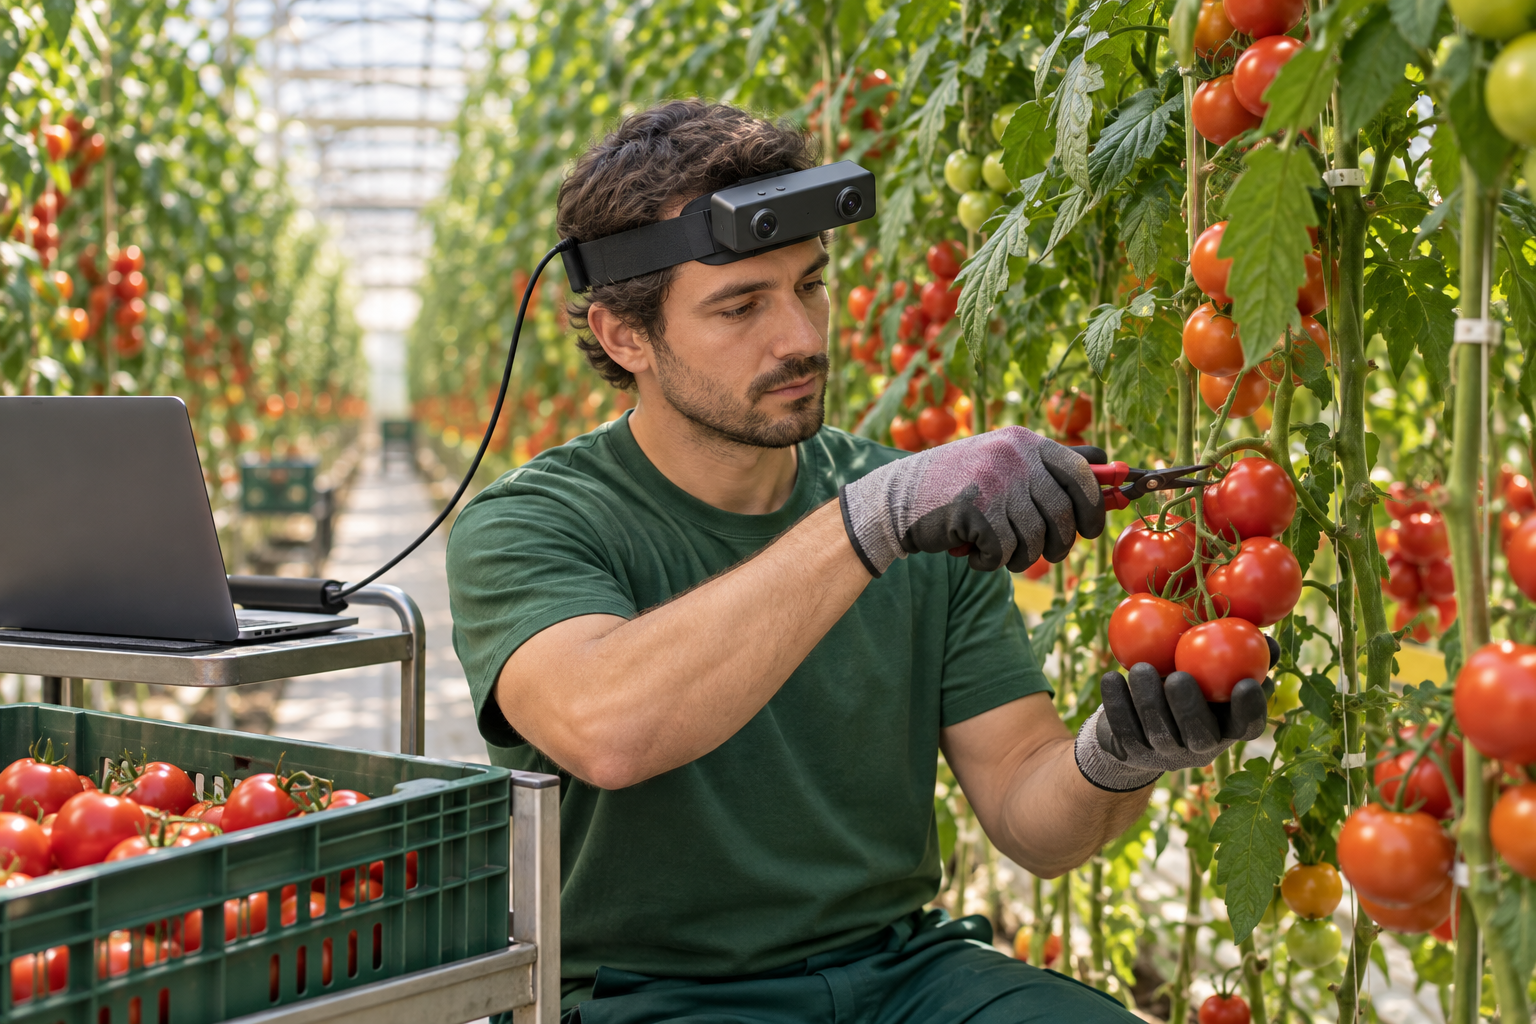
Plan a tomato harvesting dataset with EGO R8 stereo video, synchronized cameras and IMU data. Follow a greenhouse workflow from vine to crate.
Read details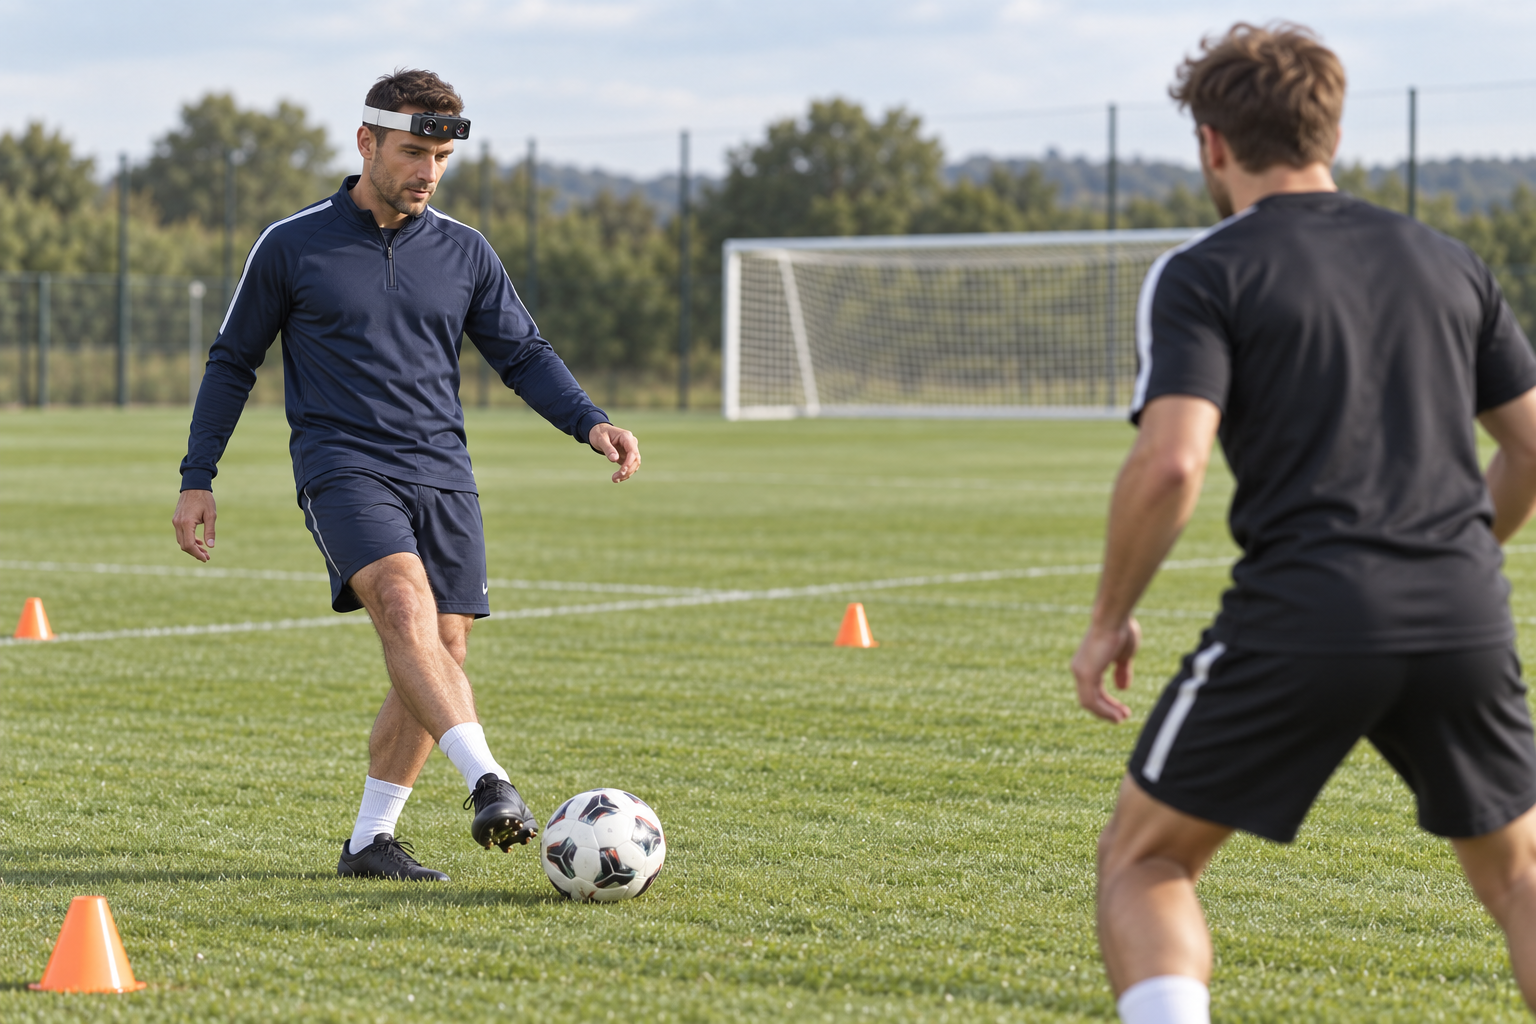
Bring the coach’s viewpoint into a football passing demonstration. EGO R9 records global-shutter video with adjustable framing, a 6-axis IMU above 200 Hz, and shared timing for reviewing the visible sequence of receiving, looking up, and passing.
Read details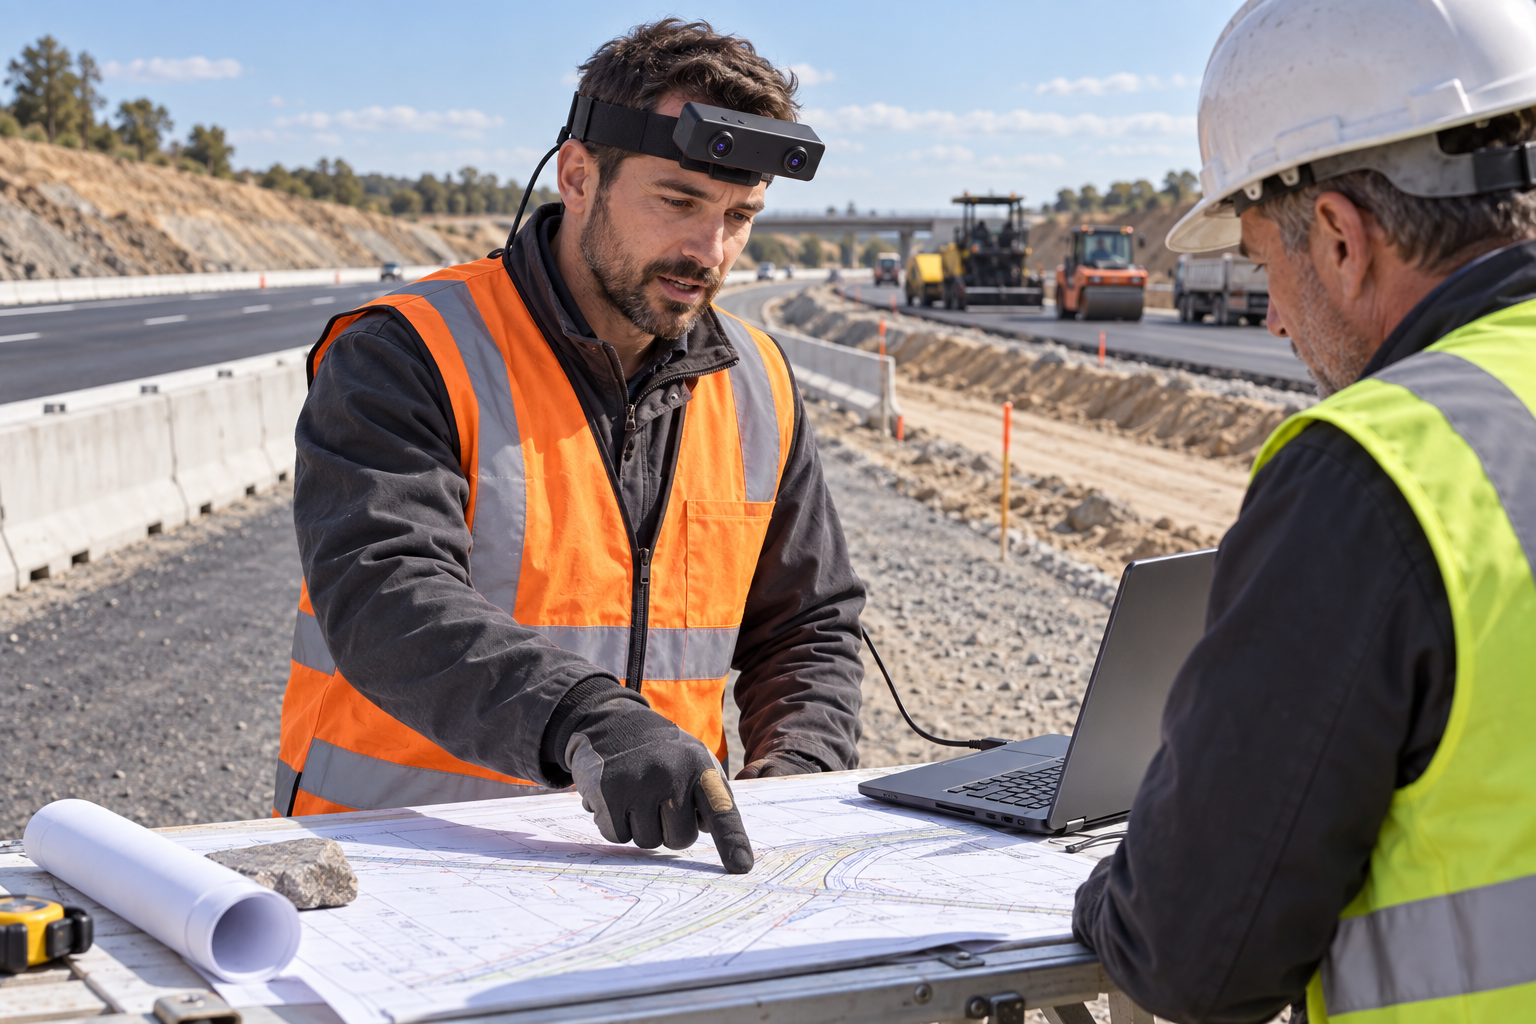
Document a highway construction workflow from the engineer’s viewpoint. EGO R8 combines synchronized dual global-shutter images, selectable IMU sampling, and unified timestamps for organized records of site demonstrations and construction handovers.
Read details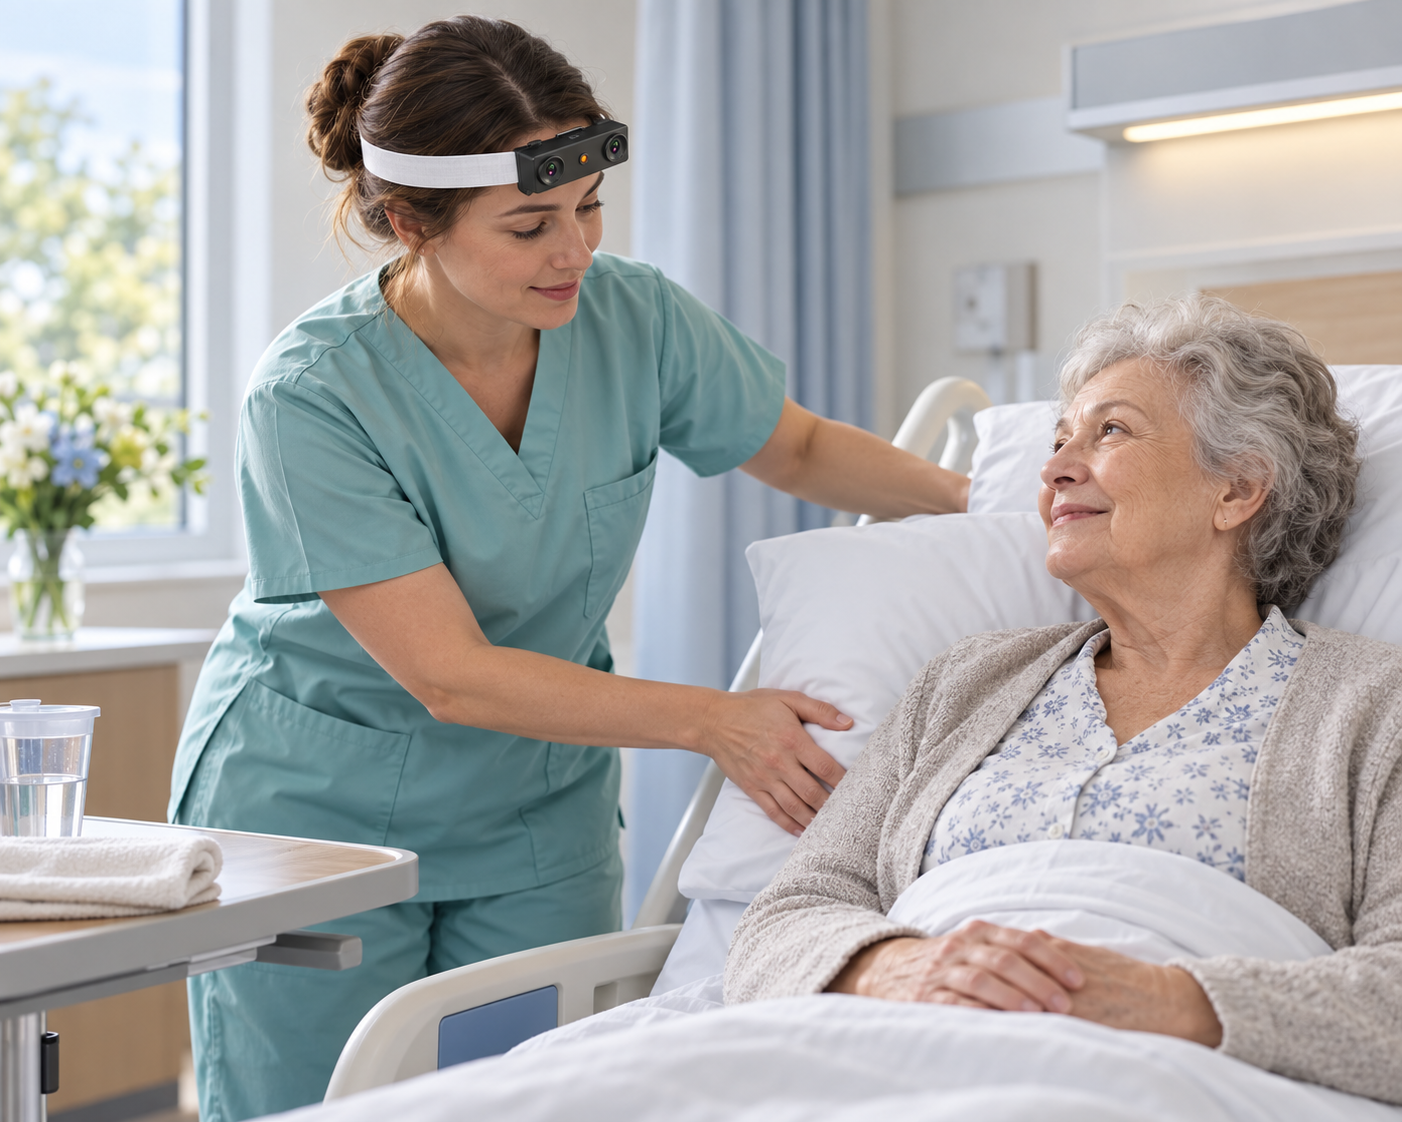
A nurse prepares bedside items, arranges a pillow, and helps an adult patient with everyday care. EGO R9 brings the caregiver’s viewpoint into focus through adjustable framing, 1080P global-shutter recording, and shared timing for image and motion data.
Read details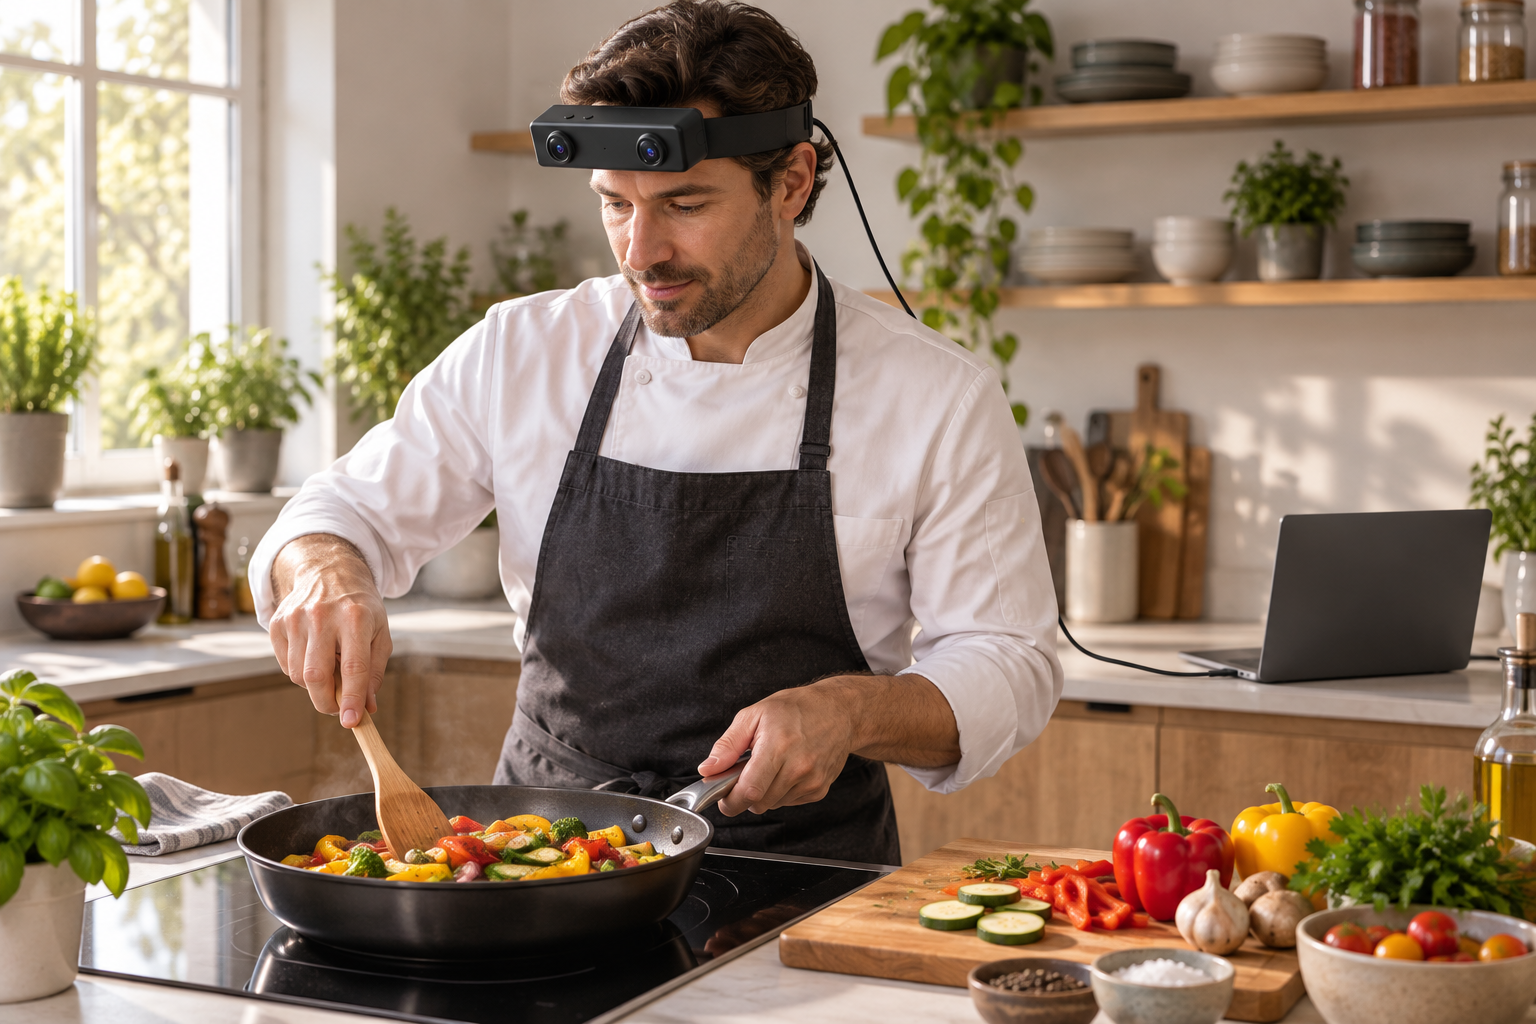
Follow a cook from ingredient preparation to stirring and plating. EGO R8 combines dual global-shutter images, hardware synchronization, selectable IMU rates, and unified timestamps to record the visible hand-and-tool sequence in a kitchen.
Read details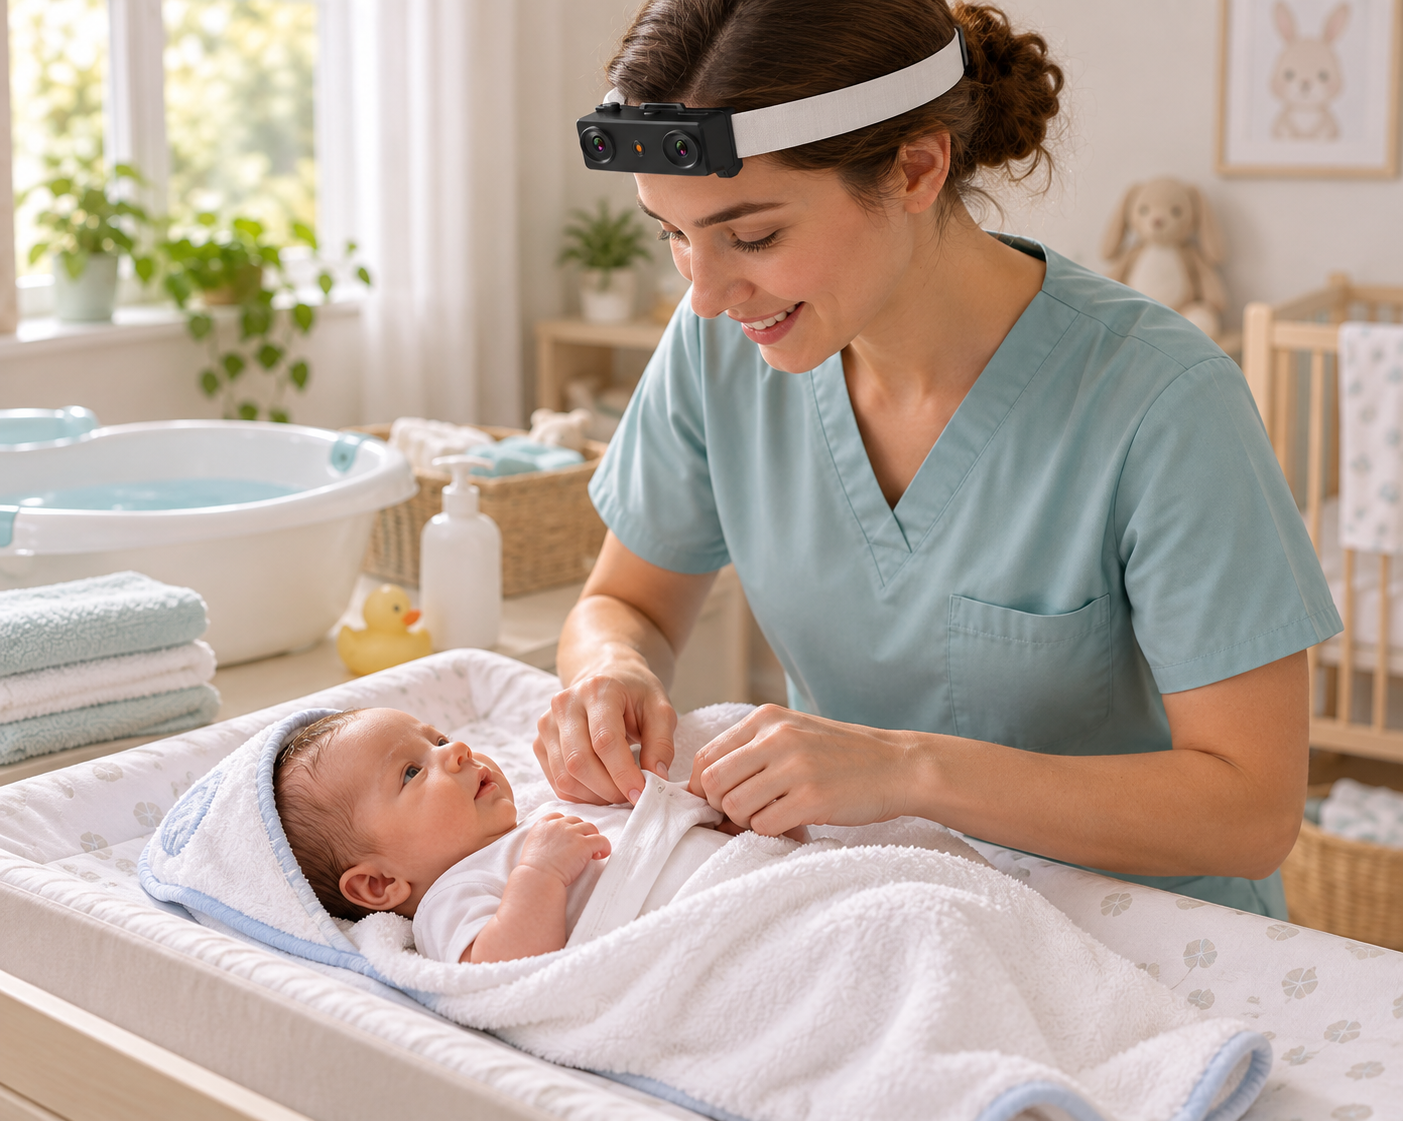
A professional caregiver gently bathes a newborn, wraps the baby in a towel, and prepares fresh clothing. EGO R9 brings a first-person view to these attentive hand movements through adjustable framing, 1080P global-shutter video, and synchronized image and motion data.
Read details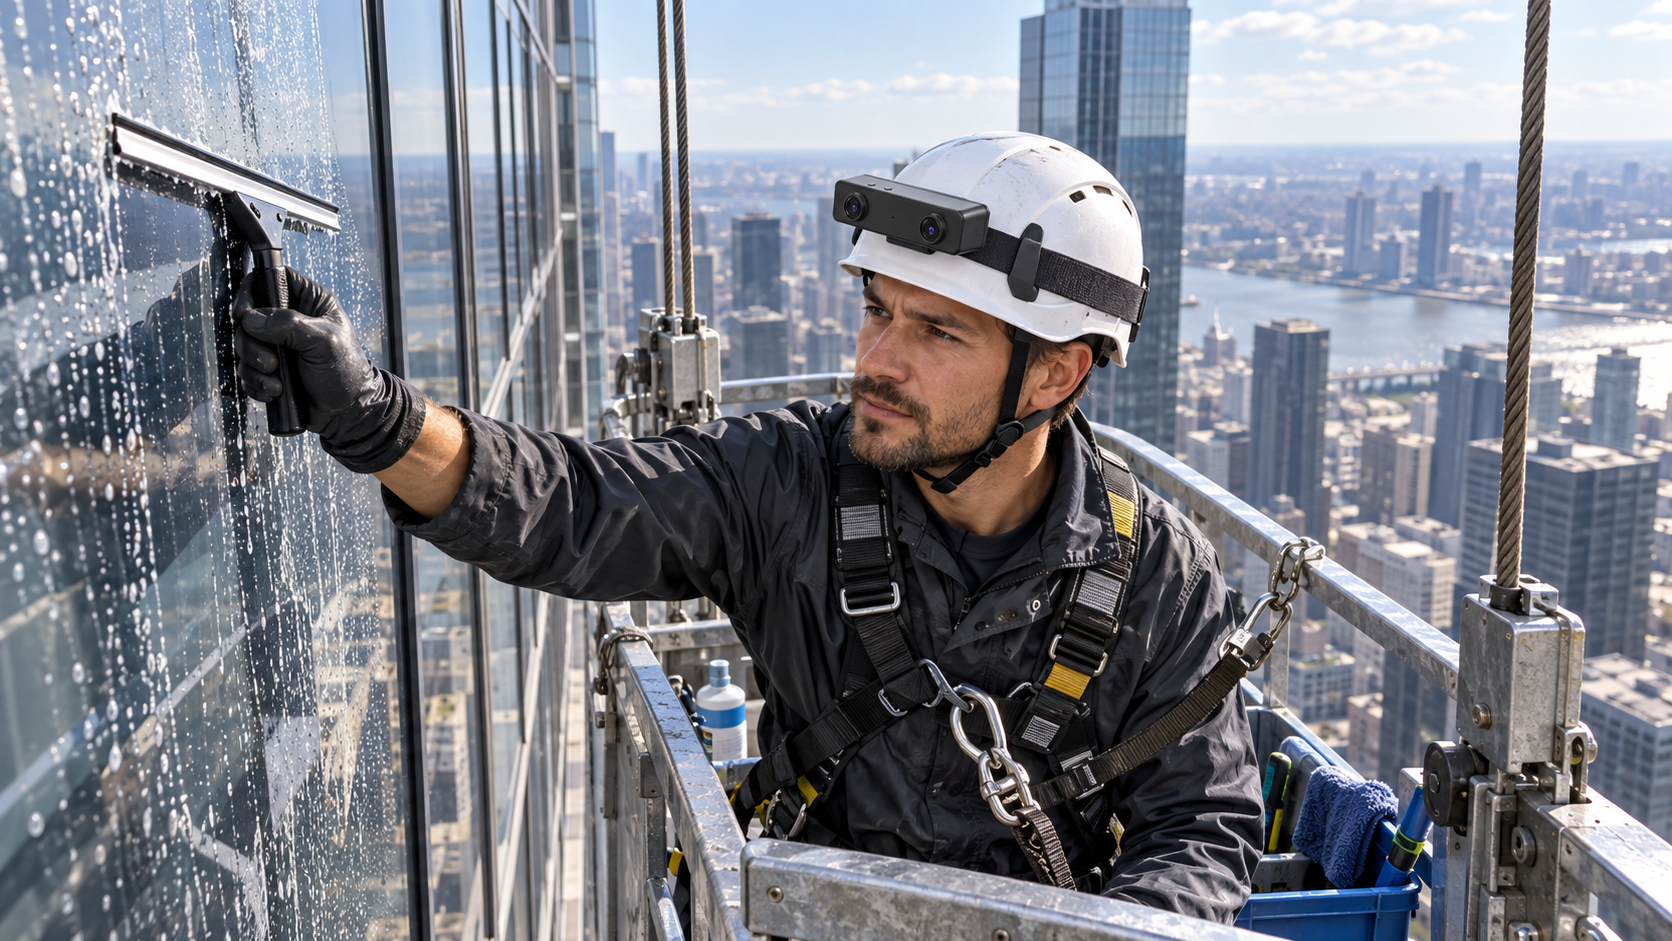
High above street level, a facade-cleaning crew works across exterior glass panels from a suspended access cradle. This EGO R8 application guide connects the visible cleaning sequence to dual global-shutter video, common hardware triggering, selectable 6-axis IMU sampling, unified timestamps, and per-unit calibration support.
Read details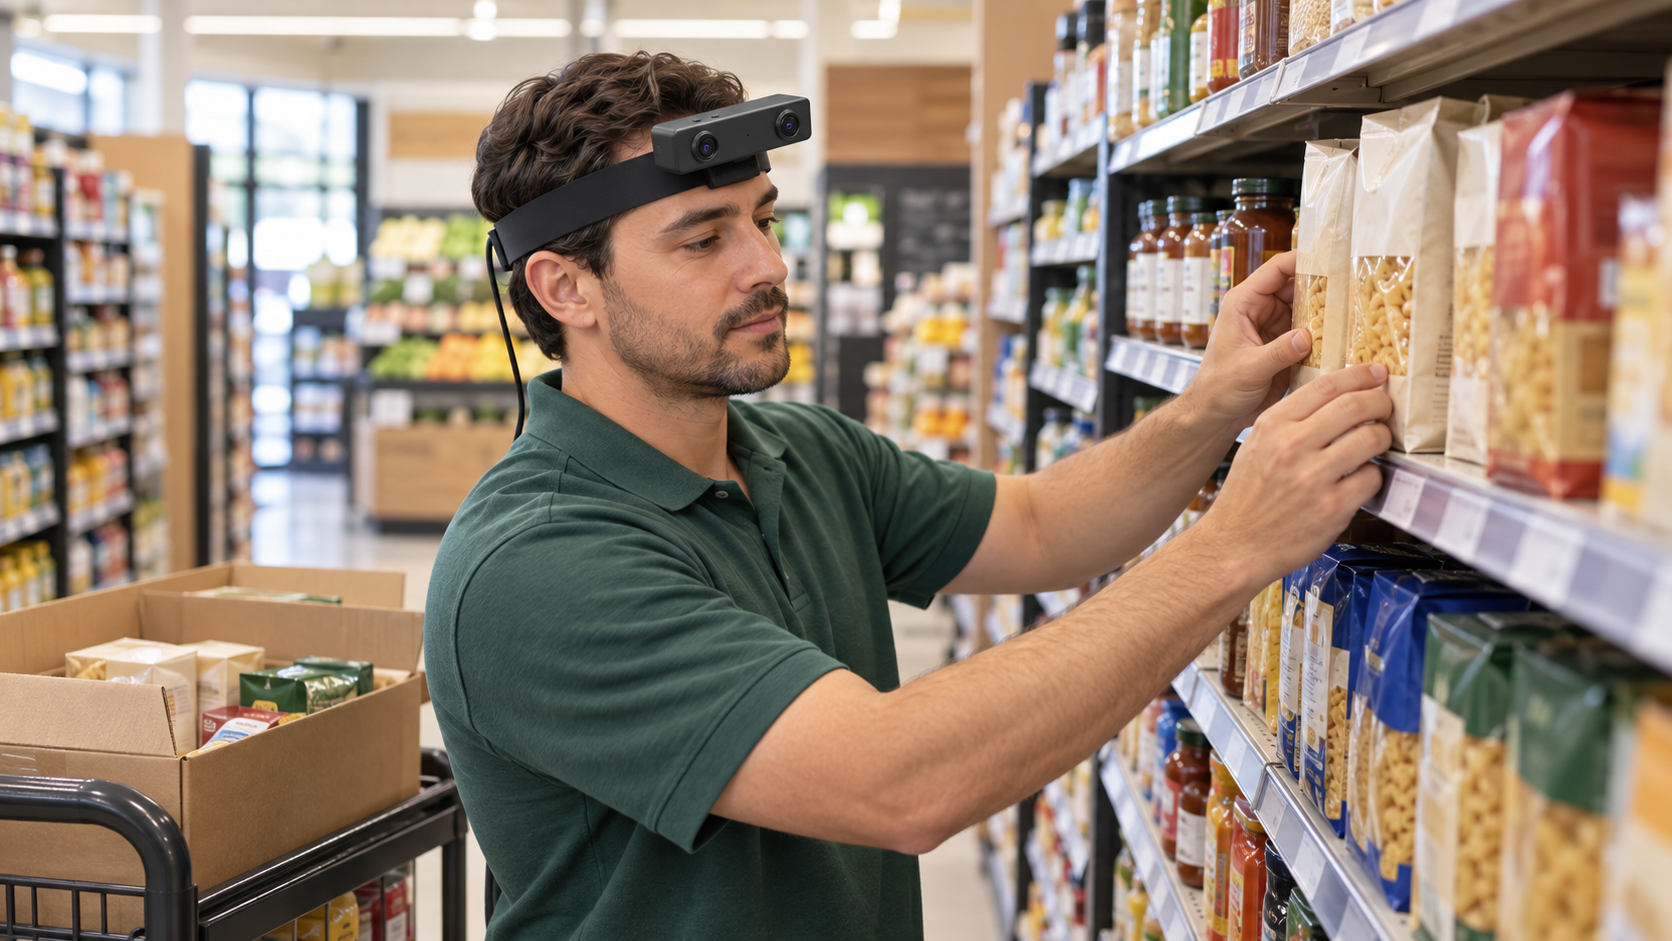
Follow a small-store replenishment round from stock-cart selection to shelf placement and final facing. EGO R8 brings dual global-shutter stereo capture, hardware synchronization, selectable IMU rates, and unified timestamps to a first-person recording of the work.
Read details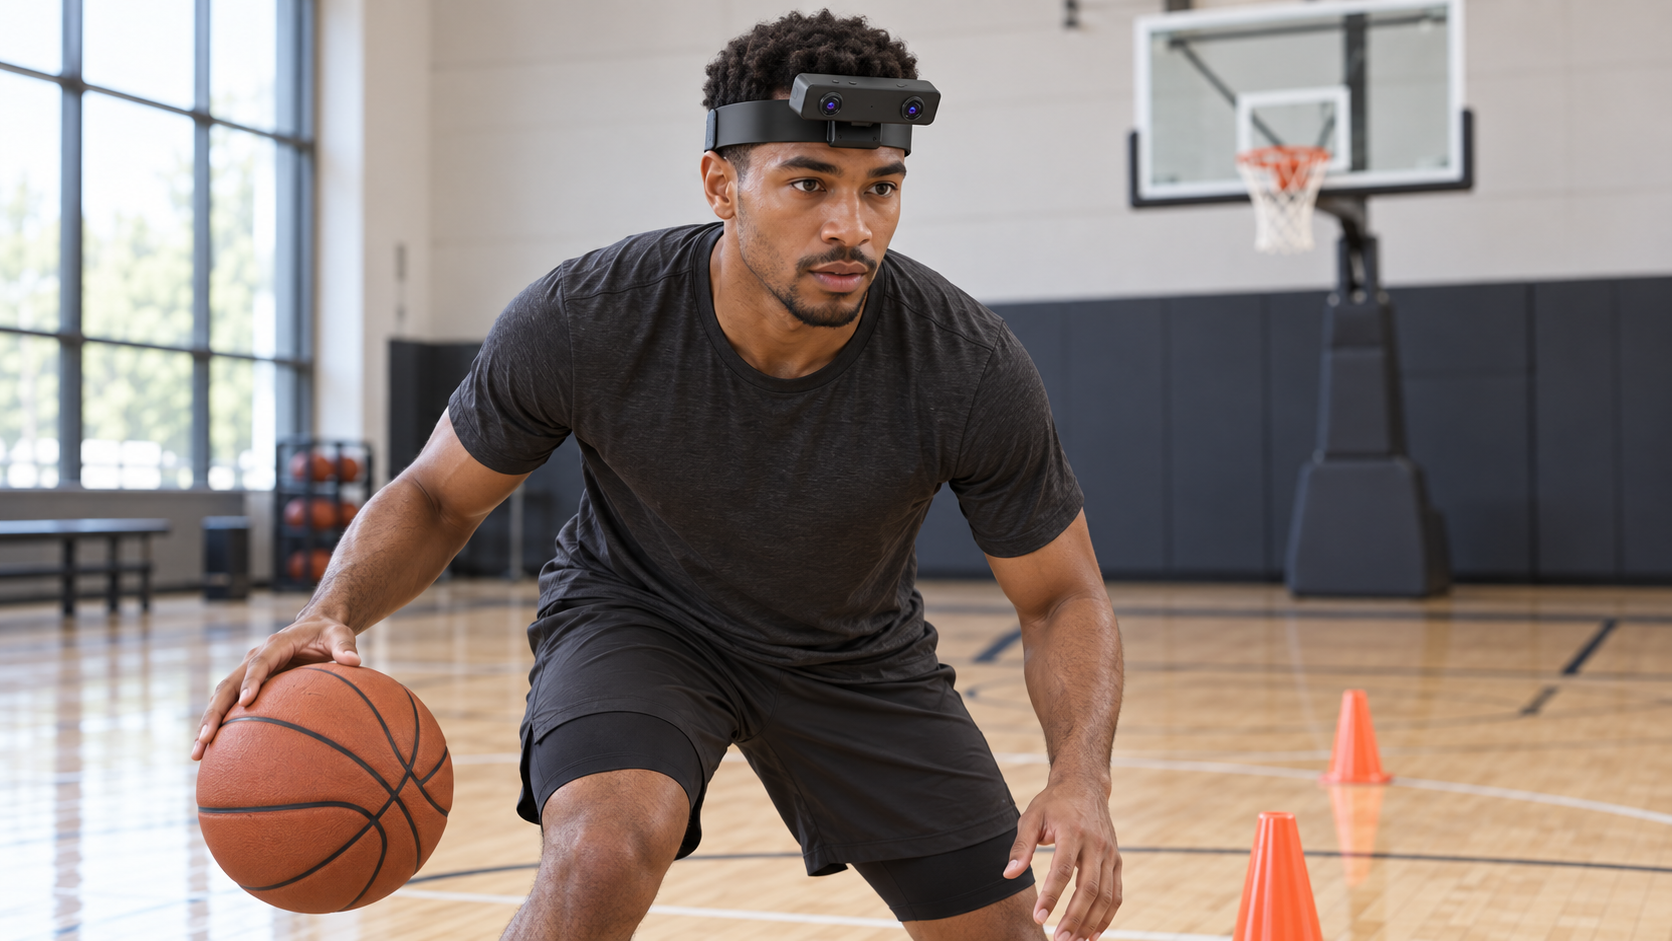
A repeatable basketball drill combines fast ball motion, hand interaction, pivots, and viewpoint changes. This guide places EGO R8 at the center of a first-person capture workflow using synchronized stereo global-shutter video, selectable-rate IMU data, unified timestamps, and per-unit calibration support.
Read details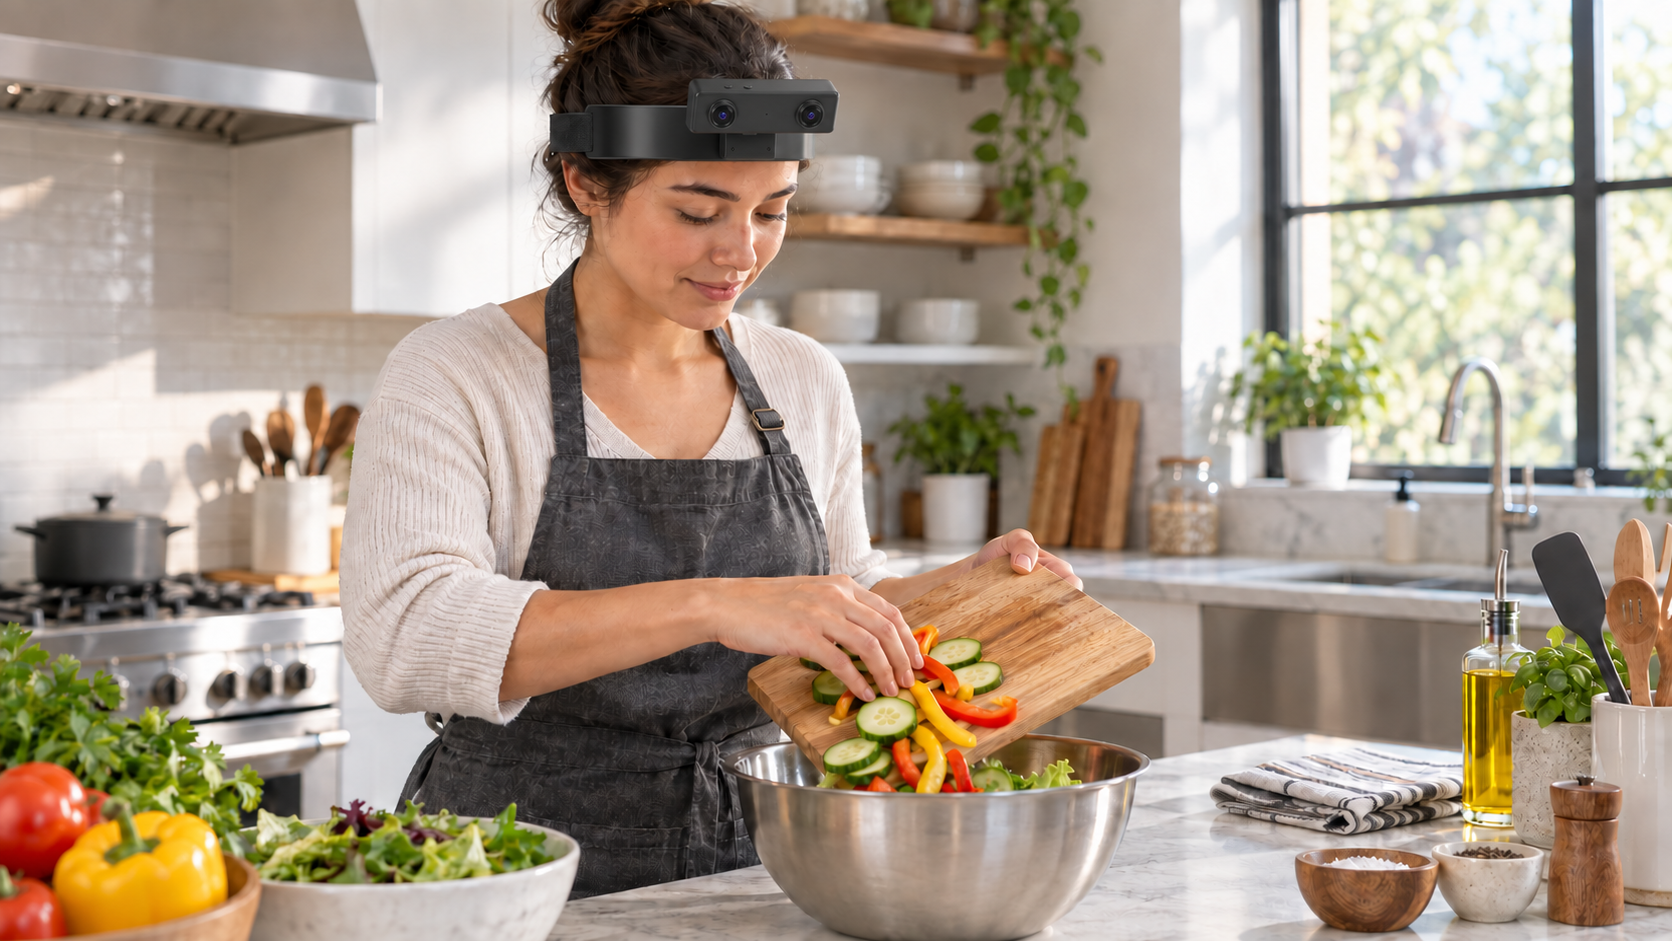
Kitchen preparation combines rapid hand motion, close object interaction, and frequent viewpoint changes. This R8 guide defines a controlled capture pilot for repeatable meal-preparation demonstrations, synchronized stereo video, inertial data, and downstream review.
Read details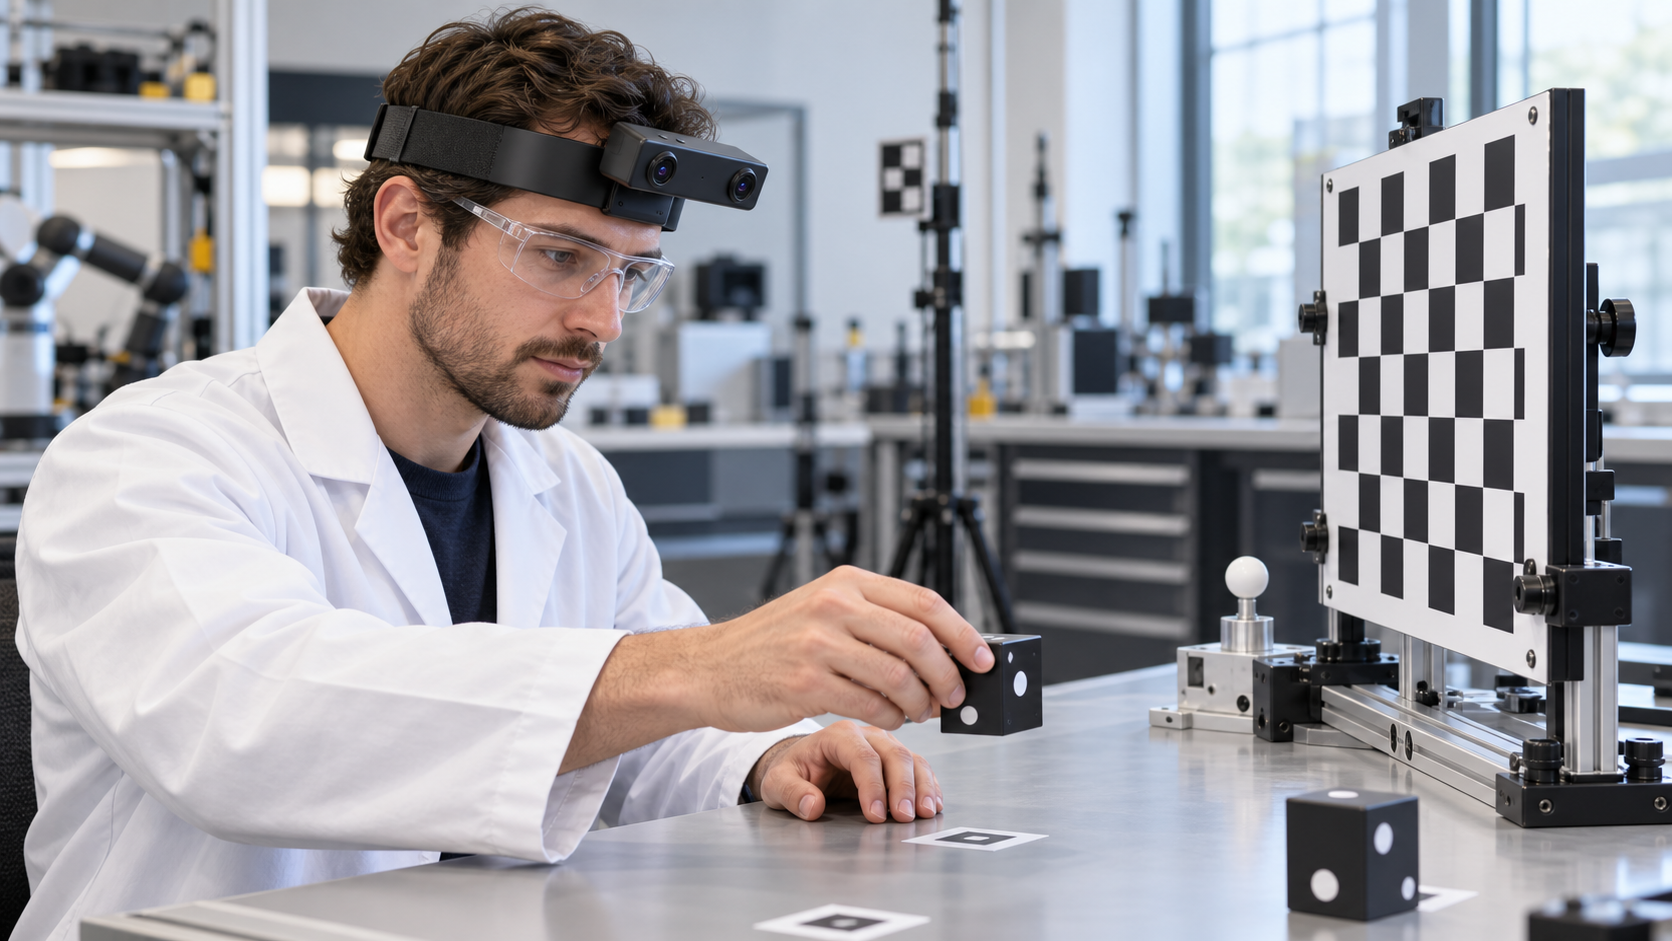
Repeatable calibration-bench movements expose timing, pairing, distortion, and data-continuity problems before a field study begins. This R8 guide turns a non-clinical laboratory setup into a structured stereo and IMU acceptance workflow.
Read details
Desk setup, cable routing, document handling, and device handoffs contain fine actions that benefit from R8's synchronized stereo global-shutter video, selectable-rate IMU, unified timestamps, and per-unit calibration support.
Read details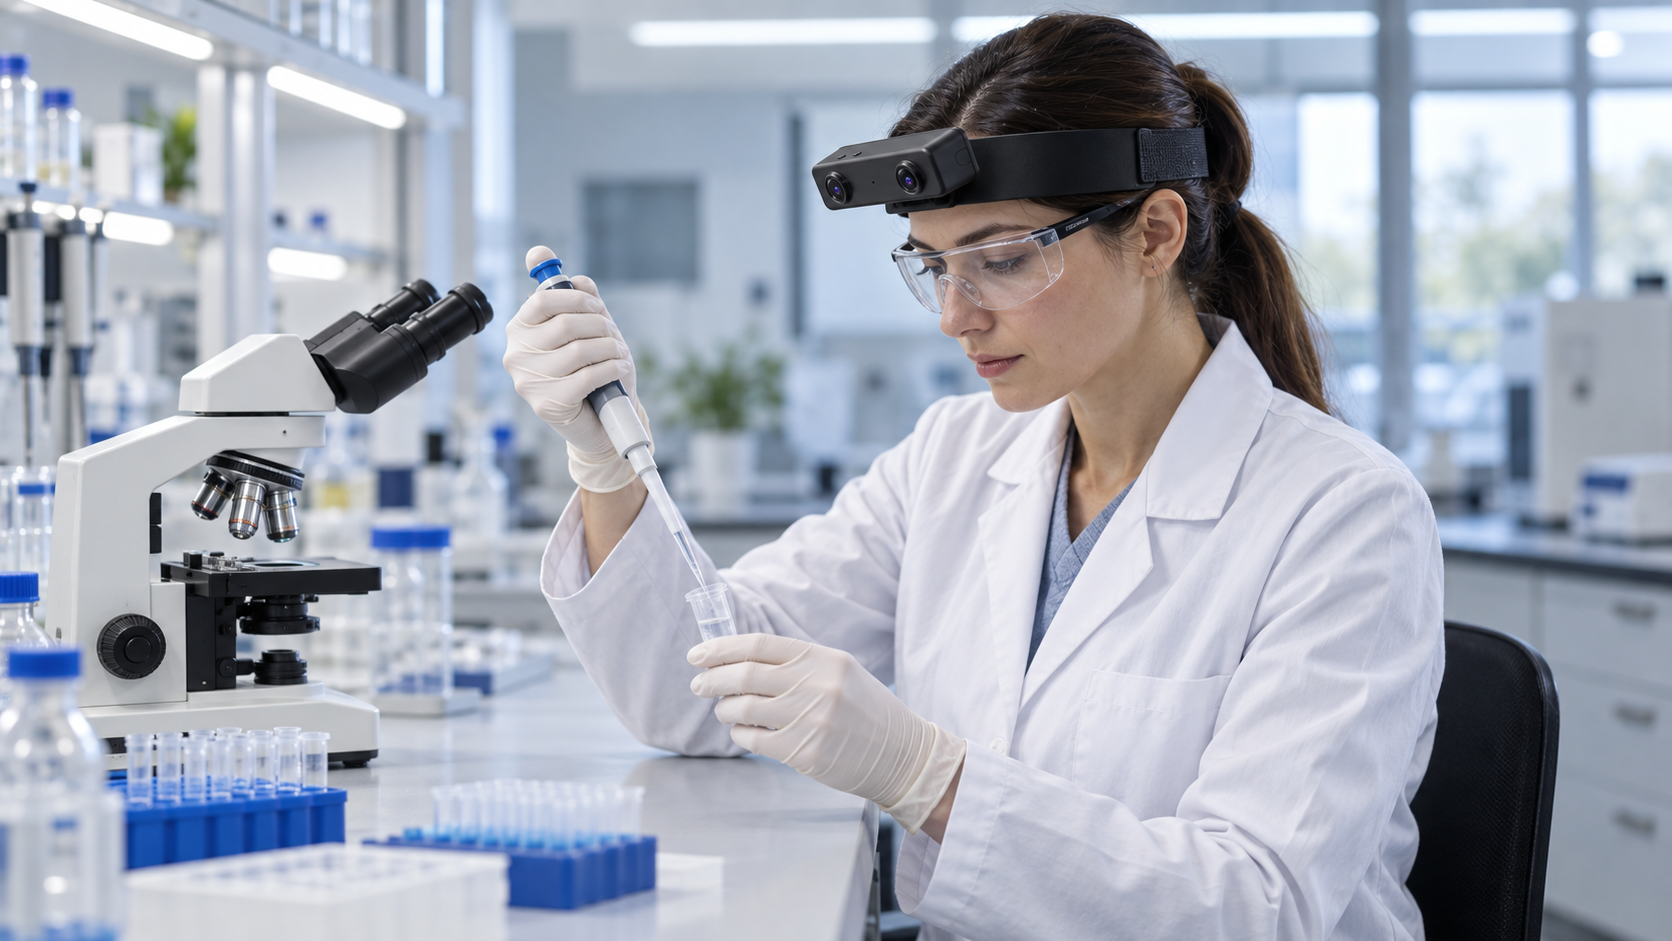
Microscope setup, pipetting, and sample handoffs combine close hand motion with frequent viewpoint changes. This R8 guide defines a laboratory pilot using synchronized stereo global-shutter video, selectable-rate IMU data, unified timestamps, and calibration support.
Read details
Fire-rescue training drills combine equipment handling, marked routes, team handoffs, and changing viewpoints. This R9 guide uses global-shutter video, high-rate IMU data, shared timing, and local recording for structured dry-drill review.
Read details
Gold-exploration work links core trays, inspection routes, and expert observations. This R9 field guide uses hands-free global-shutter video, high-rate IMU data, and shared timing to document repeatable surface geological workflows.
Read details
Feed preparation, barn rounds, and equipment checks contain practical knowledge that is difficult to capture from a fixed camera. This R9 guide describes a worker-worn recording workflow for farm training and research, with realistic image, timing, and field-use checks.
Read details
Learn how EGO R9 can capture the working sequence and clear inspection views for comparing intended states, reviewing corrections, and preparing industrial training data.
Read details
An indoor inspection route combines walking, close viewing, head turns, and repeated locations. This R9 field guide turns that route into a structured visual-inertial capture trial, using global-shutter video, high-rate IMU data, and shared timing.
Read details
A nursing-care simulation includes explanations, pauses, attention shifts, and hand movements. This R9 field guide uses wide-angle global-shutter video, high-rate IMU data, shared timing, and local recording for structured review.
Read details
Shared reading, toy cleanup, and preparing to leave home contain small but meaningful care interactions. This R9 guide turns selected adult-led routines into reviewable first-person recordings, with clear framing, timing, and family privacy boundaries.
Read details
Opening a jar, weighing ingredients, and returning a lid are separate learning events. Inspired by HD-EPIC, this practical R9 guide shows how to capture continuous kitchen activity that reviewers can segment, verify, and reuse.
Read details
A useful demonstration preserves the full change from approach to completed placement. This EGO R9 guide uses global-shutter video, high-rate IMU data, and shared timing to capture reviewable task transitions.
Read details
A manipulation demonstration loses value when the hand, object, or goal disappears behind a drawer, tool, or robot arm. Inspired by EgoAVFlow, this guide shows how R9 teams can collect visibility-aware first-person data and test it before scale-up.
Read details
EgoHumanoid moves human demonstration beyond tabletop manipulation into walking, reaching, carrying, and placing across real environments. EGO R9 can support similar field capture when viewpoint, route, timing, and task boundaries are designed together.
Read details
EgoScale links more than 20,000 hours of action-labelled human egocentric video to stronger dexterous transfer. For R9 teams, the practical lesson is to scale task diversity, visibility, timing, and quality controls together.
Read details
This field protocol connects natural hand-object demonstrations with R9 image, IMU, timestamp, storage, and recovery checks for repeatable embodied-AI data collection.
Read details
Robotics data programs rarely move directly from one prototype to hundreds of devices. EGO R9 gives teams a confirmed first-person capture foundation while engineering, validation, and manufacturing controls support the path from concept to pilot fleet.
Read details
Ego-OSCAR's 550-hour release highlights the operational discipline behind large egocentric datasets. EGO R9 supplies confirmed global-shutter video, high-rate inertial data, and shared timing for repeatable field collection.
Read details
EGO R9 combines 1080P global-shutter imaging, a 120-degree first-person view, a 6-axis IMU above 200 Hz, and shared timing for motion-rich embodied-AI datasets.
Read details
Ego2Robot shows that even short first-person demonstrations can become useful robot training signals after action retargeting, visual alignment, and quality control. EGO R9 can strengthen the capture layer for precision assembly and maintenance workflows.
Read details
EGO R9 combines 1080P global-shutter video, a 6-axis IMU above 200 Hz, a shared clock, and global timestamps to preserve the timing of first-person manipulation demonstrations.
Read details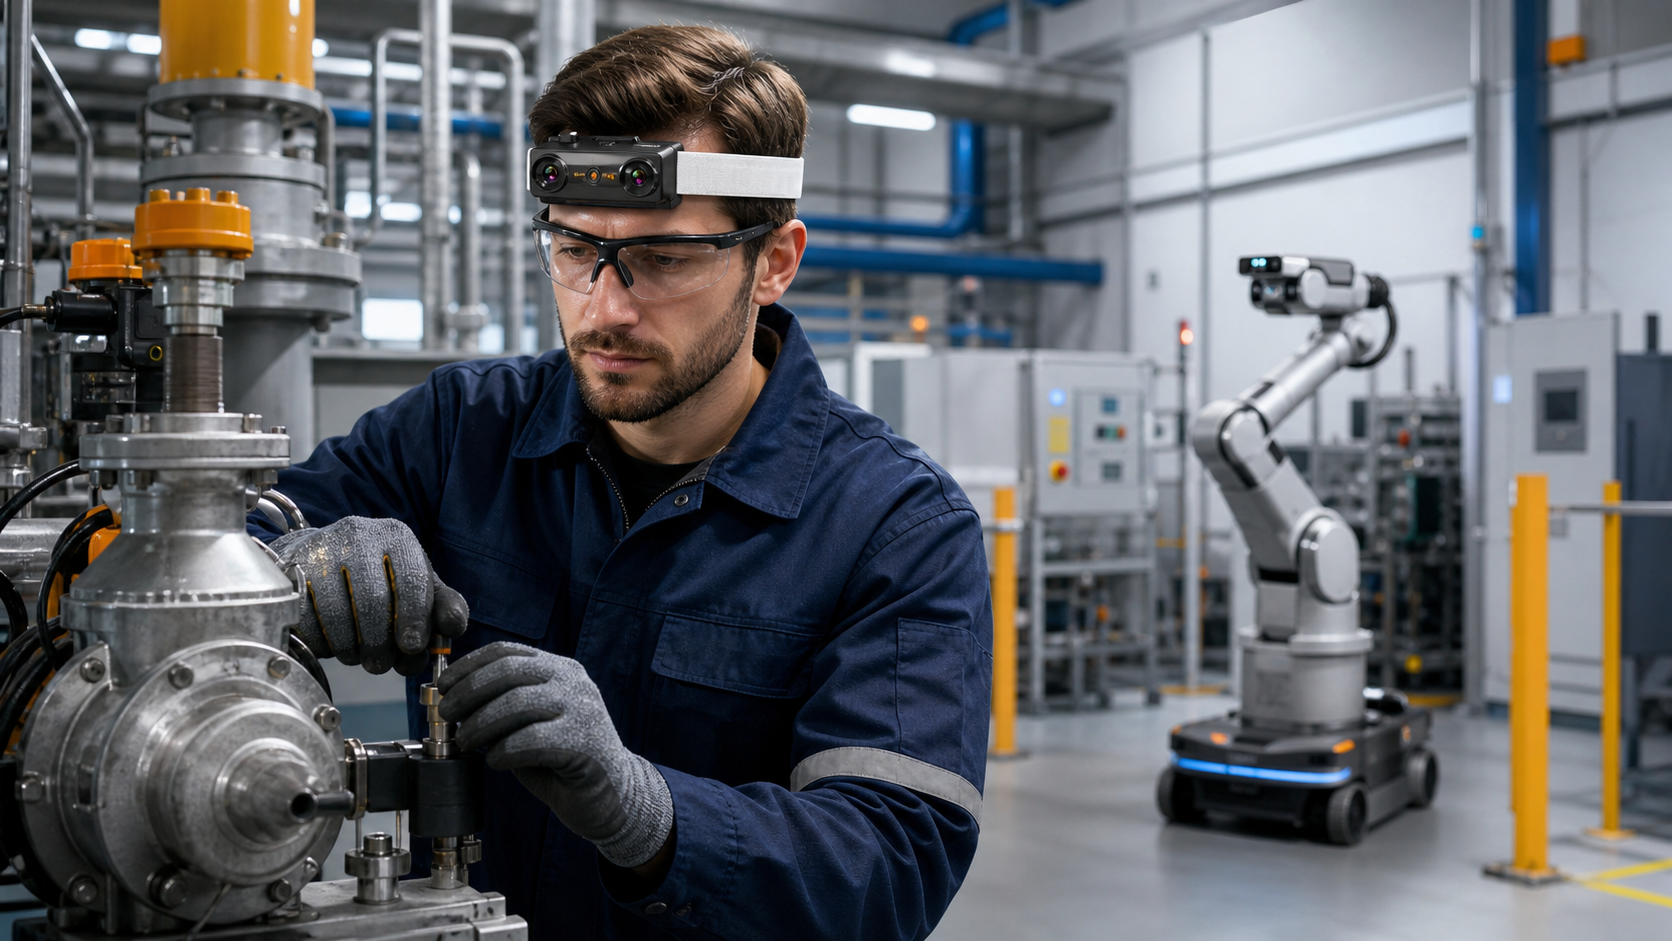
Robots learn physical work best from data that preserves what a skilled person sees, how the hands move, and when each decision occurs. EGO R9 provides a practical first-person capture layer for building that evidence at scale.
Read details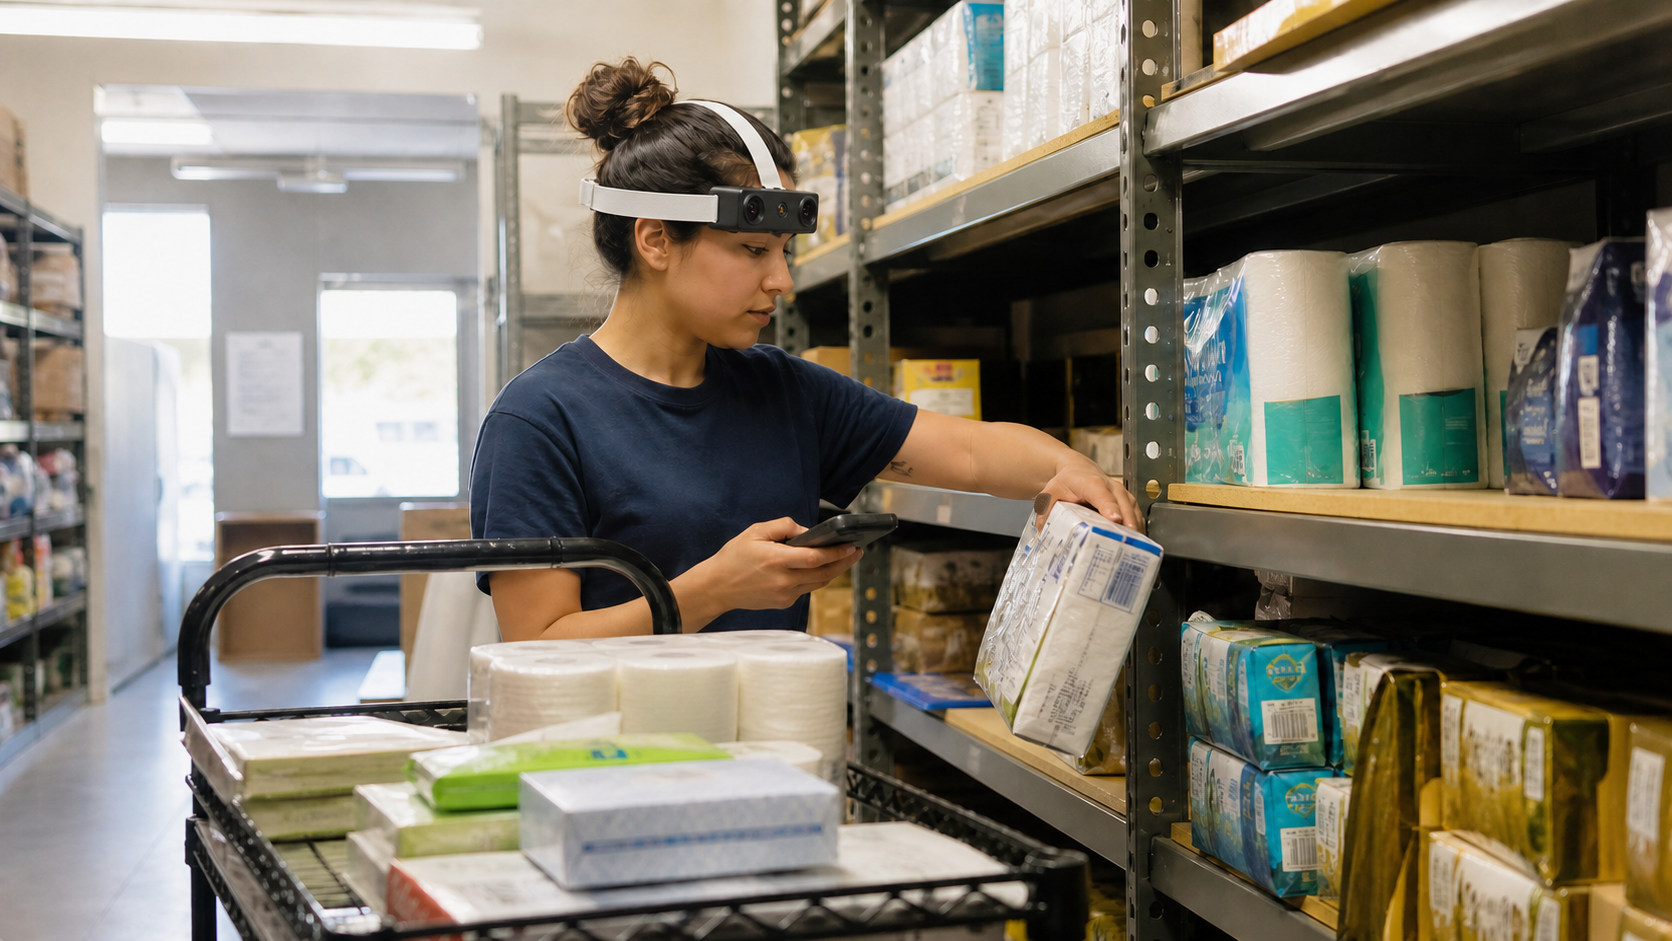
Routine work such as scanning, sorting, restocking, packing, and tidying contains the hand-object sequences robots need to learn. Ego2Robot shows how first-person demonstrations could be transformed at scale.
Read details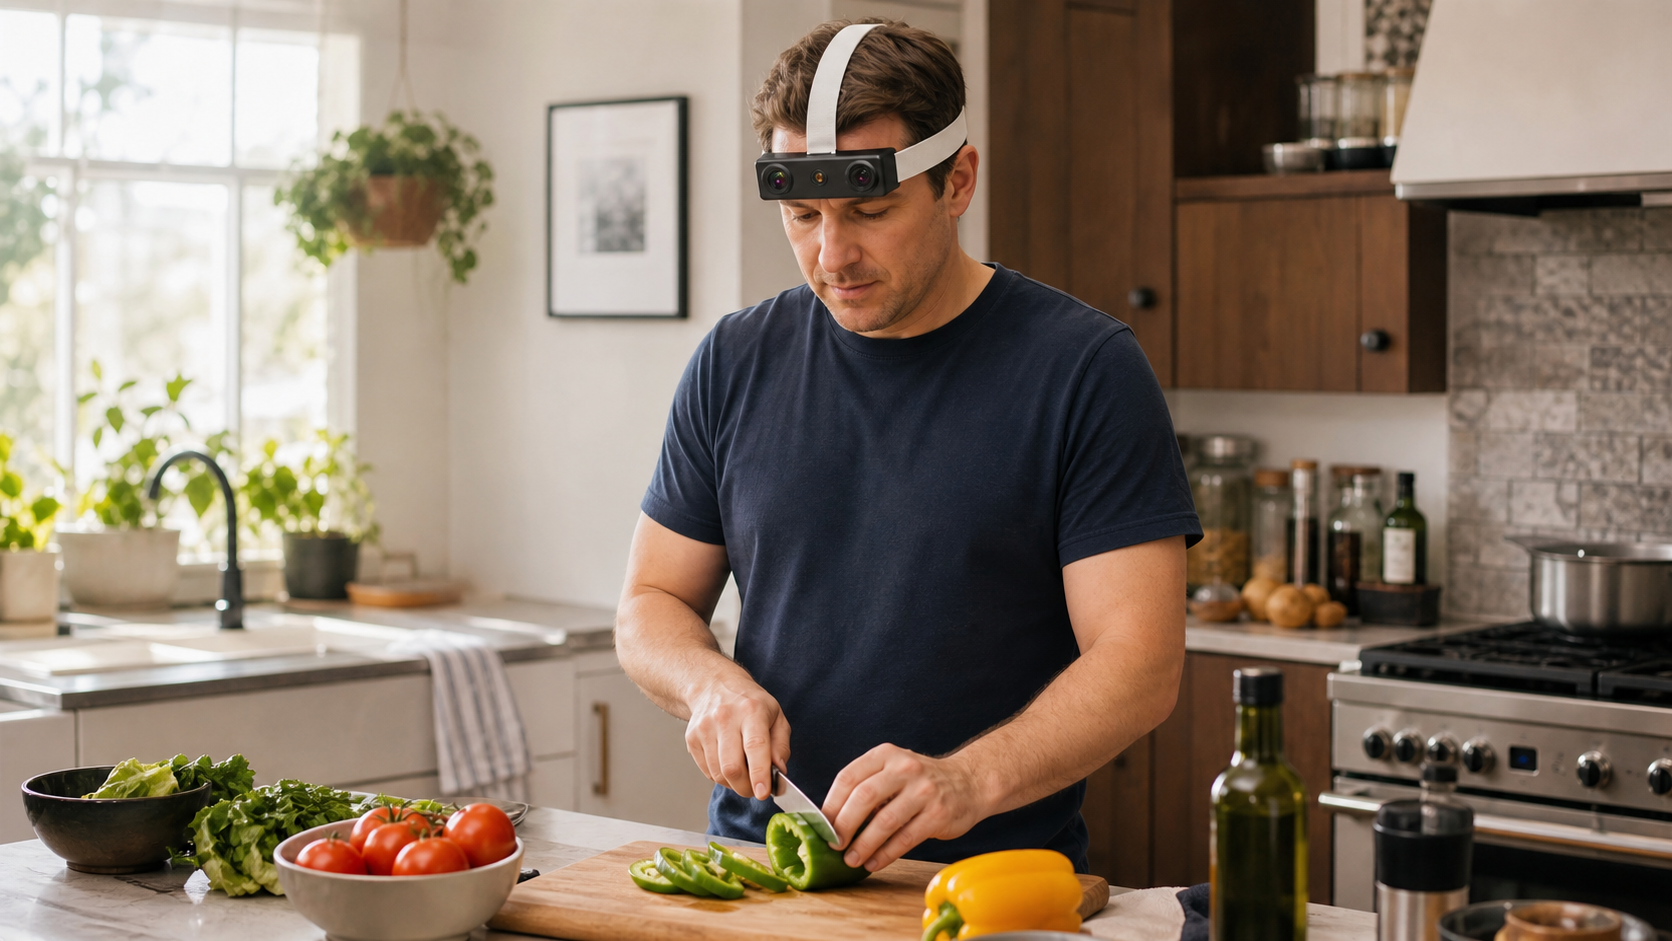
Cooking, cleaning, organizing, and simple repairs contain rich contact and motion patterns. EgoInfinity illustrates how ordinary video can be lifted into structured 4D hand-object interaction data.
Read details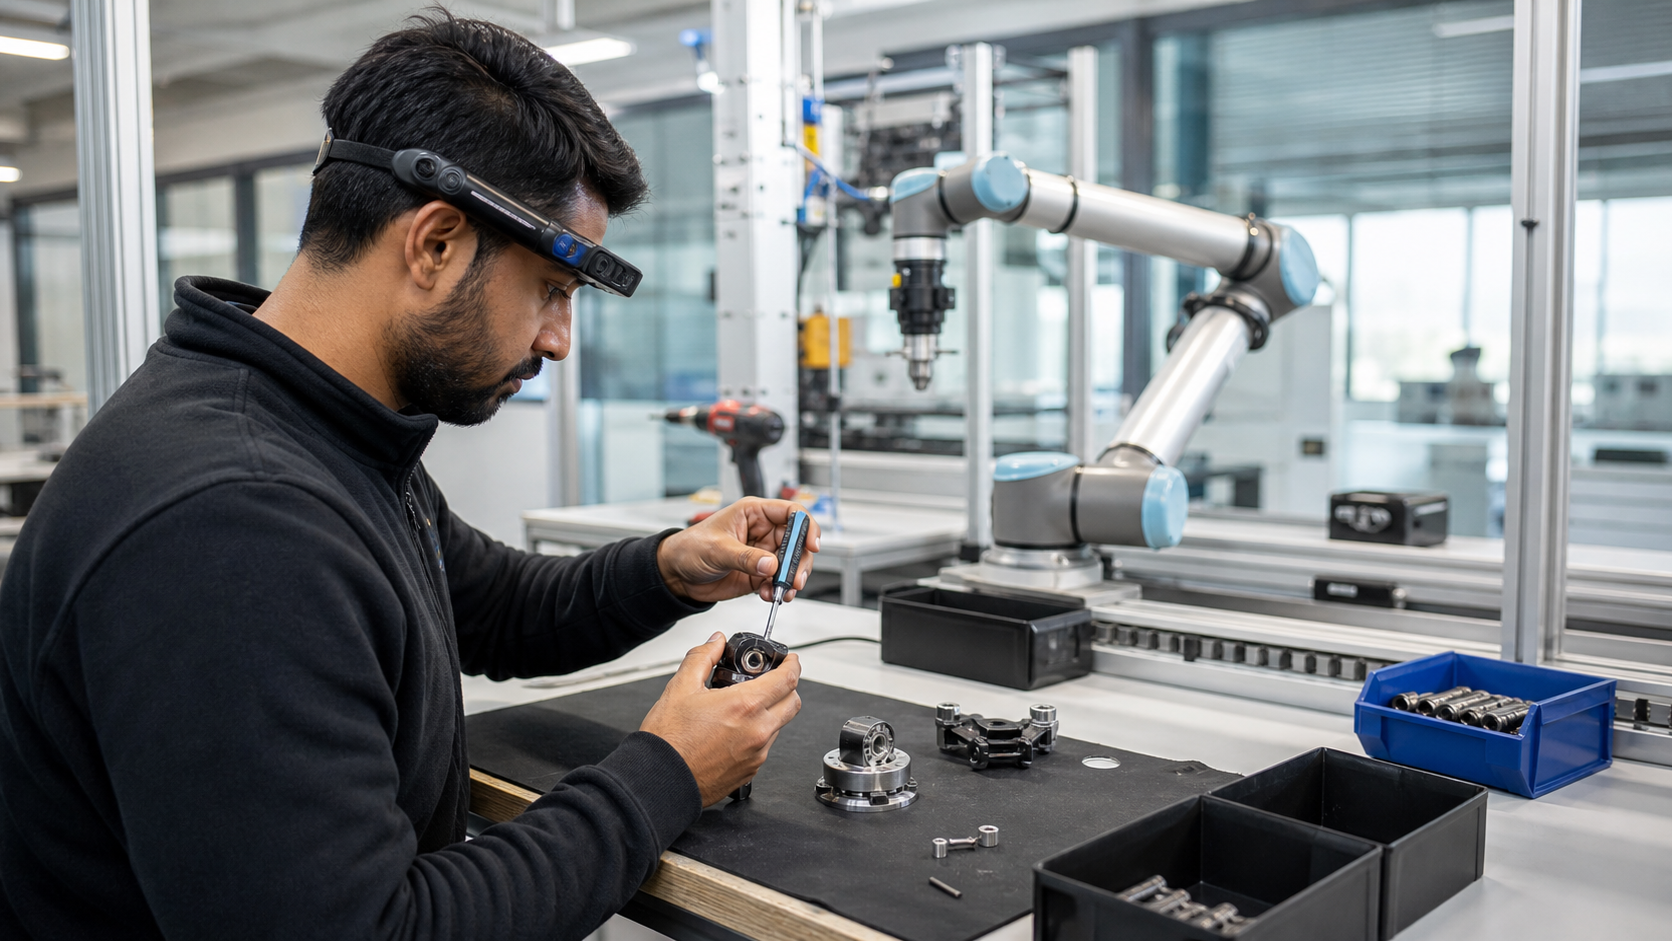
The next leap in robotics depends on more than stronger models. It requires structured, physically realistic data that teaches machines how people perceive, move, manipulate objects, and complete real tasks.
Read details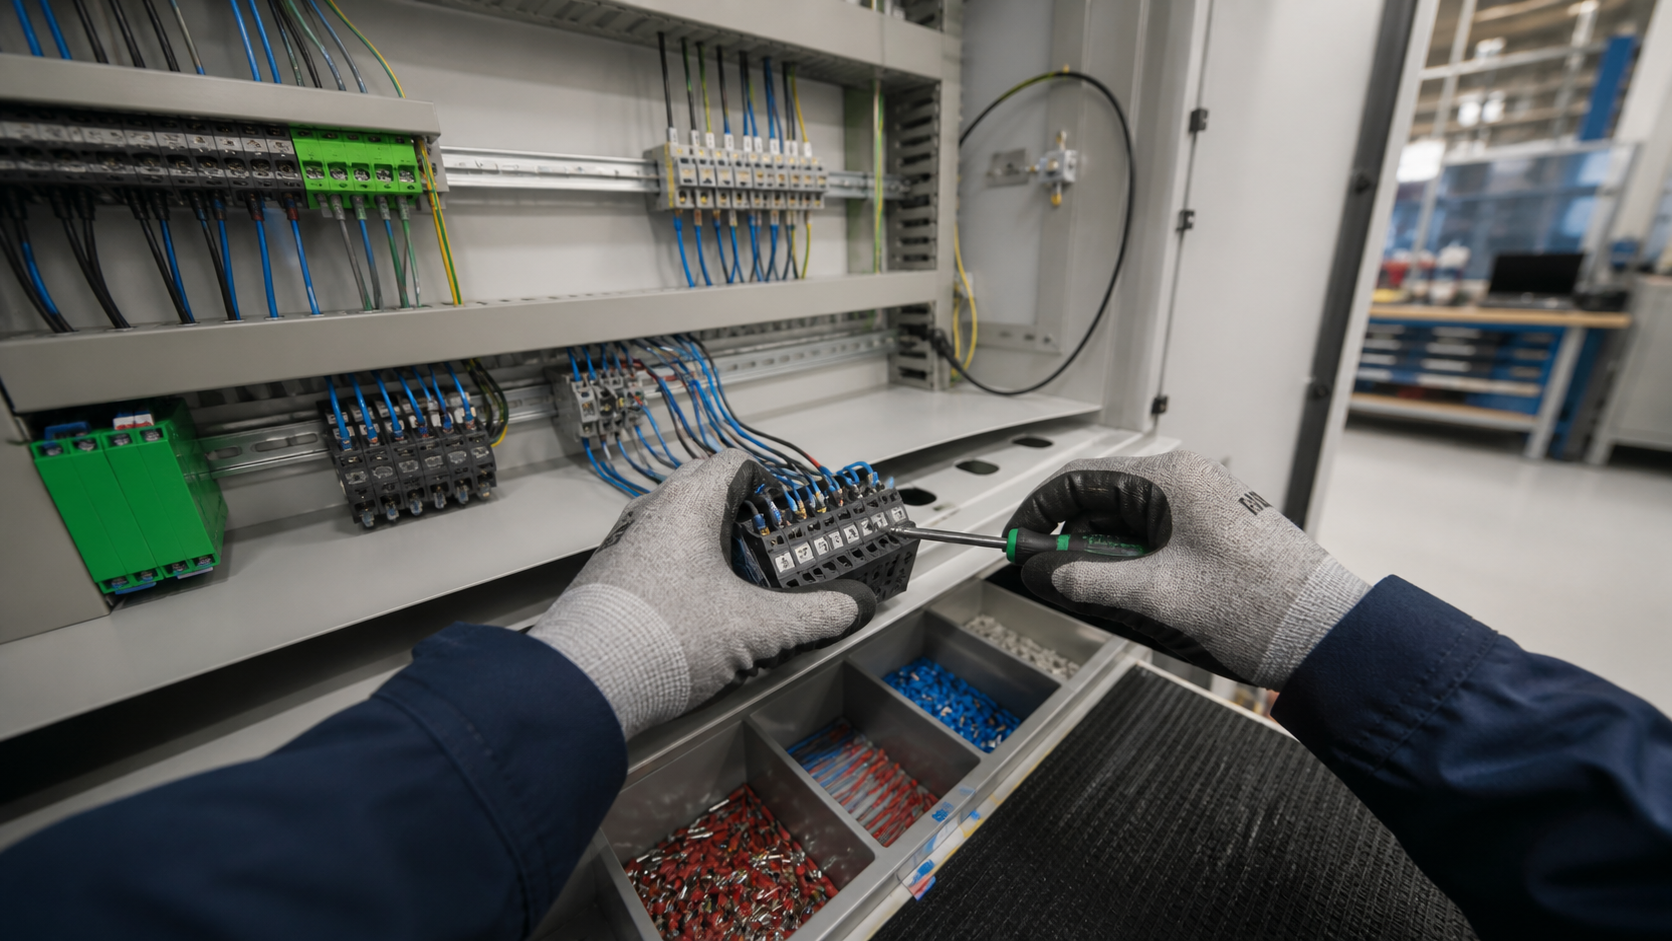
Why first-person demonstrations are becoming the essential bridge between capable AI models and robots that can work safely in the physical world.
Read details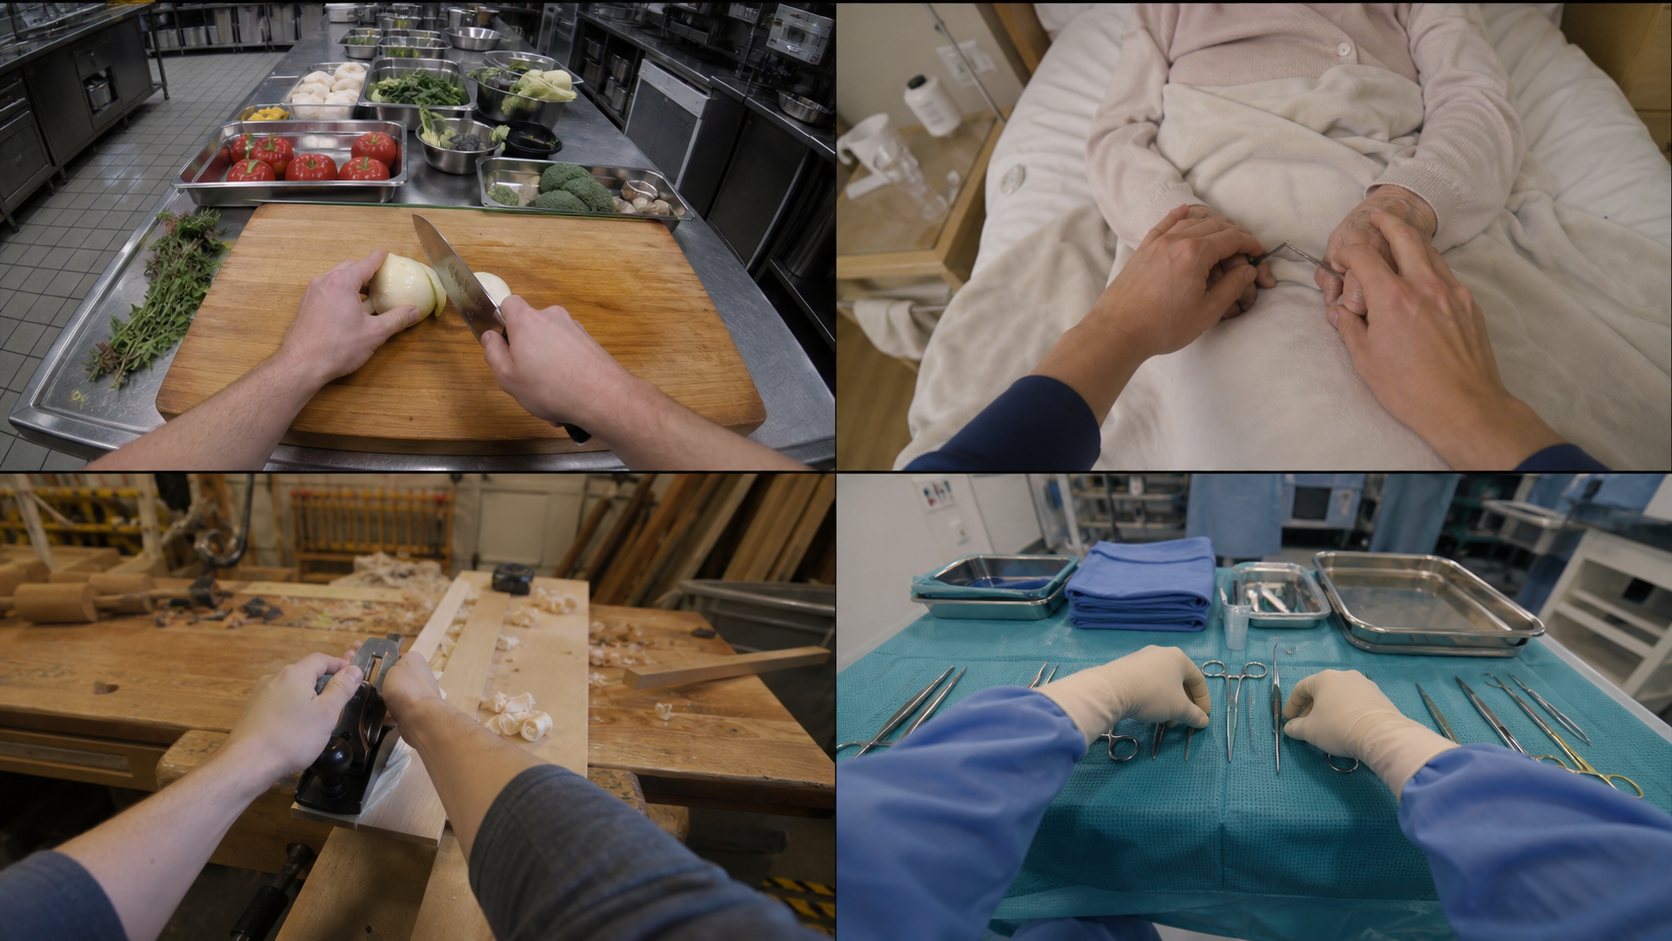
A practical look at how consistent first-person R9 capture can turn cooking, household care, craft, and training workflows into structured learning material for robots.
Read details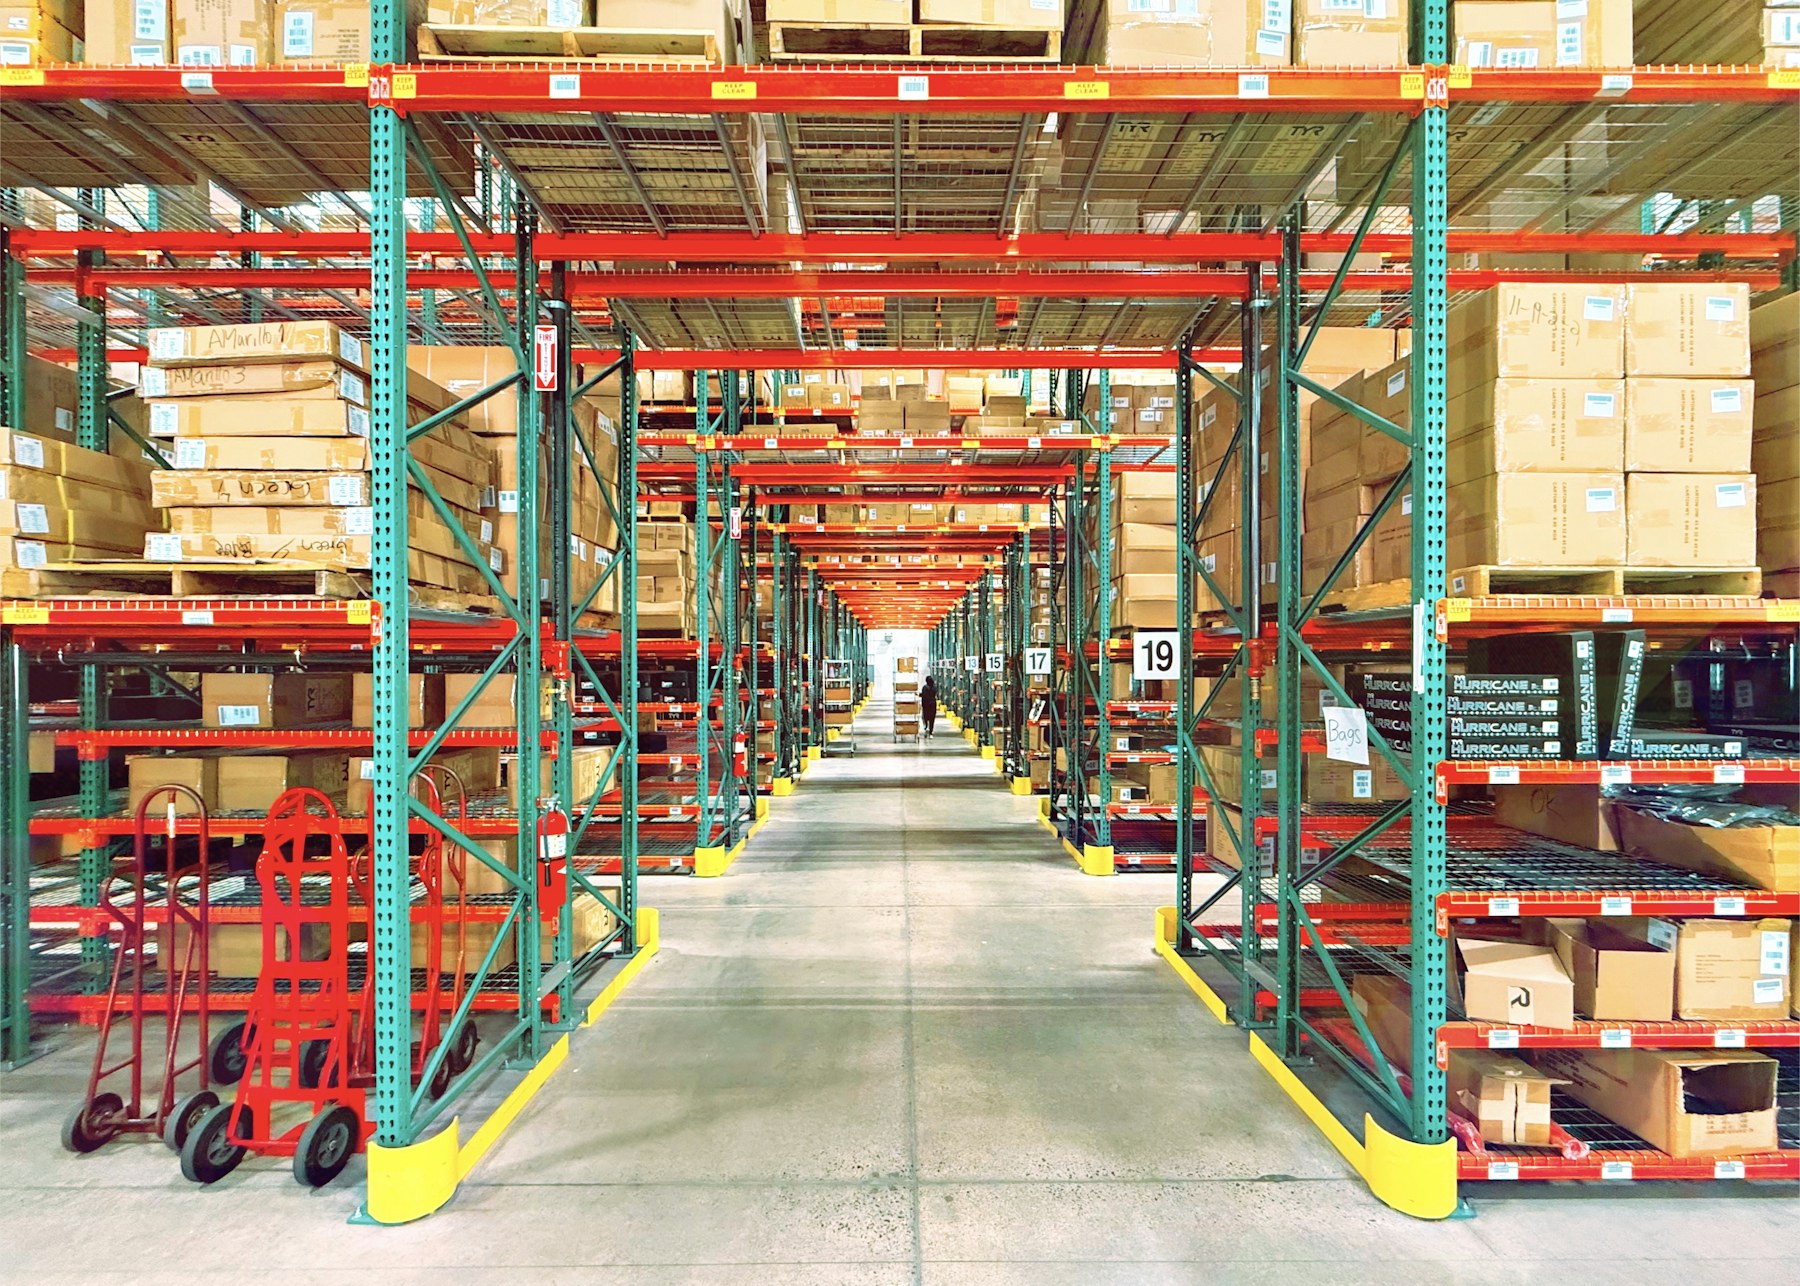
A practical field guide to collecting first-person pick, scan, carry, and exception-handling data with U.S. warehouse associates—while protecting safety, privacy, and worker trust.
Read details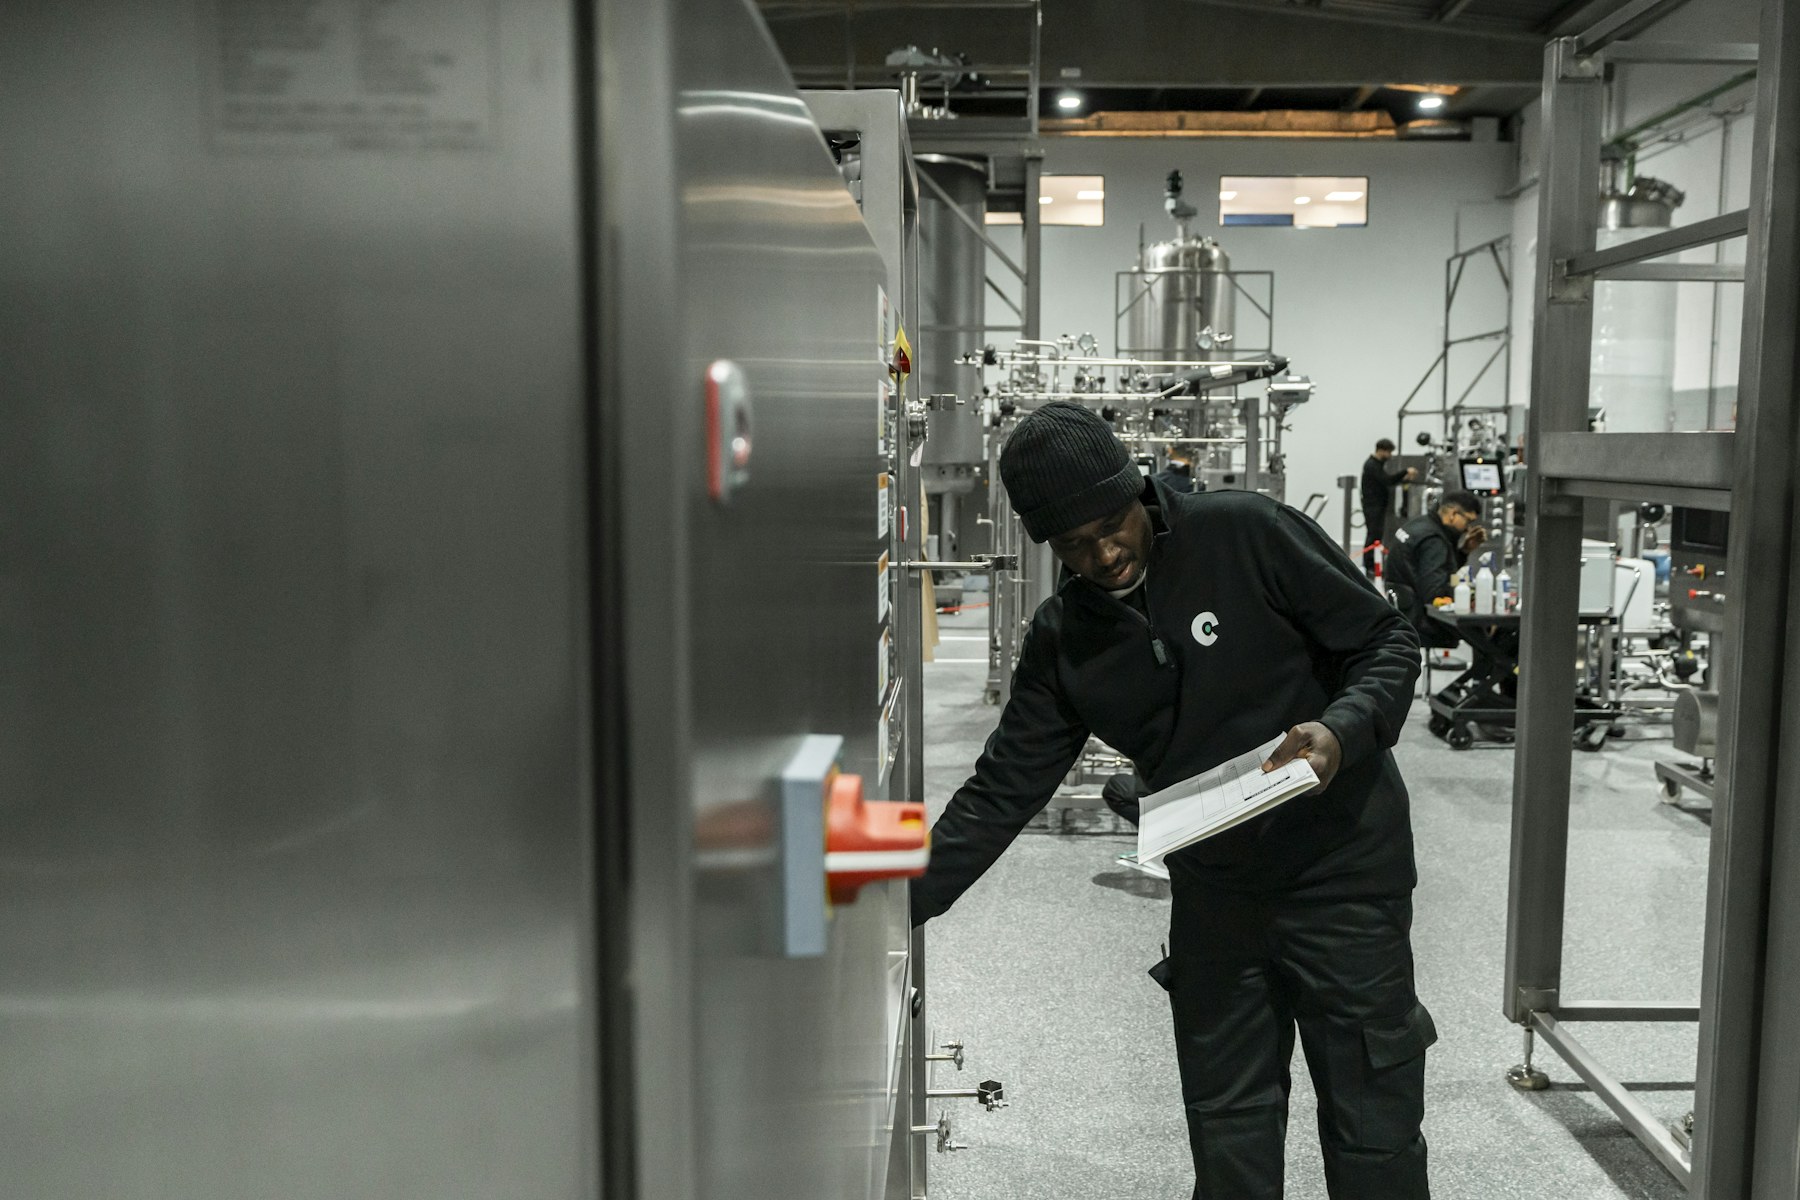
How first-person recordings from industrial machinery mechanics can preserve troubleshooting know-how, build procedural datasets, and support safer AI-assisted training.
Read details
High-quality first-person datasets depend on clear task design, visible hand-object interaction, stable timing, traceable metadata, and consistent review from pilot capture through delivery.
Read details
Coupled egocentric control maps operator head and arm motion into coordinated torso and base behavior for whole-body robot teleoperation.
Read details
Exo2EgoPose uses exocentric demonstrations to guide vision-language prediction of future 3D hand poses from dynamic egocentric observations.
Read details
EgoExoMoCap combines egocentric and exocentric signals from people wearing head-mounted devices to reconstruct real-world human motion.
Read details
AeroAct predicts smooth quadrotor trajectory-action chunks from egocentric visual history, proprioception, and language-conditioned goals.
Read details
Ego Scene Augmentation builds an Ego-element Graph to strengthen spatial reasoning by multimodal language models in first-person scenes.
Read details
MEMORA organizes egocentric experience into editable environment, entity, activity, and inferred-knowledge stores for long-horizon robot planning.
Read details
EgoEngine converts egocentric human manipulation video into a robot-view observation sequence and a task-aligned executable action trajectory.
Read details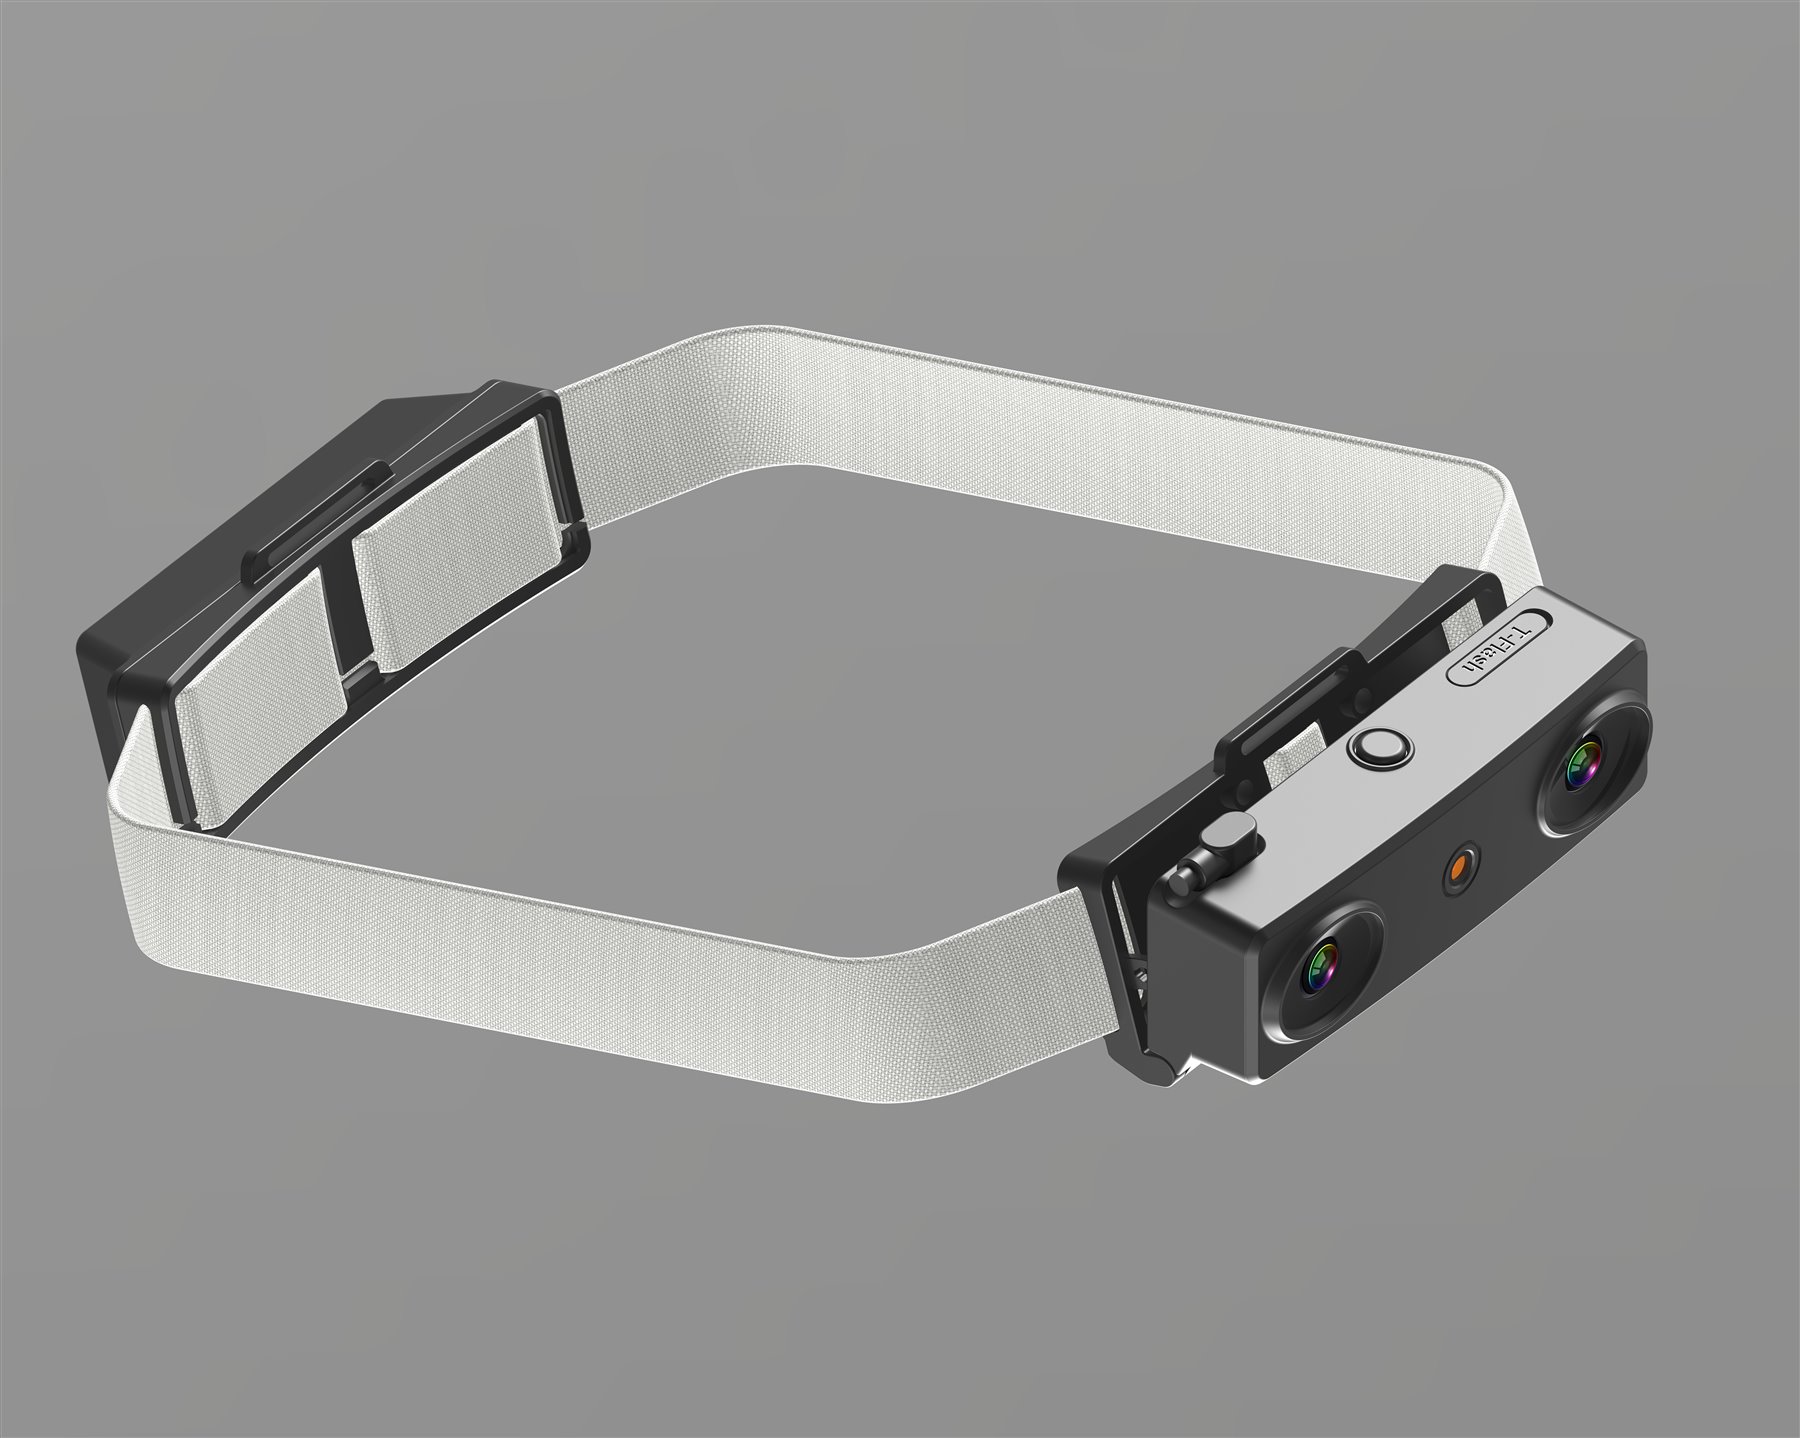
HumanEgo turns minutes of human egocentric manipulation video into entity-level hand-object representations for zero-shot transfer to robot policies.
Read details
This Human-to-Robot pipeline separates video understanding from robot imitation, turning observed actions and objects into structured manipulation skills.
Read details
EgoMimic co-trains on human egocentric demonstrations and robot data through 3D hand tracking, cross-domain alignment, and an imitation-learning architecture.
Read details
Ego-Exo4D pairs synchronized first- and third-person recordings of skilled activities across 1,286 hours, 740 participants, 13 cities, and 123 natural settings.
Read details
Ego4D established a large-scale benchmark for first-person perception with 3,670 hours of daily-life video from 931 wearers across 74 locations in nine countries.
Read details